Model: CACR-SR15BB1BM
Series: CACR-SR ServoPack
Rated Motor Power: 1.5 kW
Rated Output Current: 8.5 A
Input Voltage: Three-phase 200 VAC to 230 VAC, 50/60 Hz
Control Modes: Position, speed, torque
Position Command: Pulse train, differential or open-collector
Analog Command: 0 VDC to 10 VDC speed or torque
Encoder Feedback: Incremental A/B/Z; selected variants support absolute encoder
Speed Response: 1 kHz
Protection Rating: IP20
Cooling: Self-cooled
Operating Temperature: 0°C to 40°C; certain configuration records list up to 55°C
Dimensions: 150 mm width, 260 mm height, 190 mm depth
Weight: Approximately 3.5 kg
Functional Features:
Vector Control: Stable low-speed torque and smooth high-speed operation
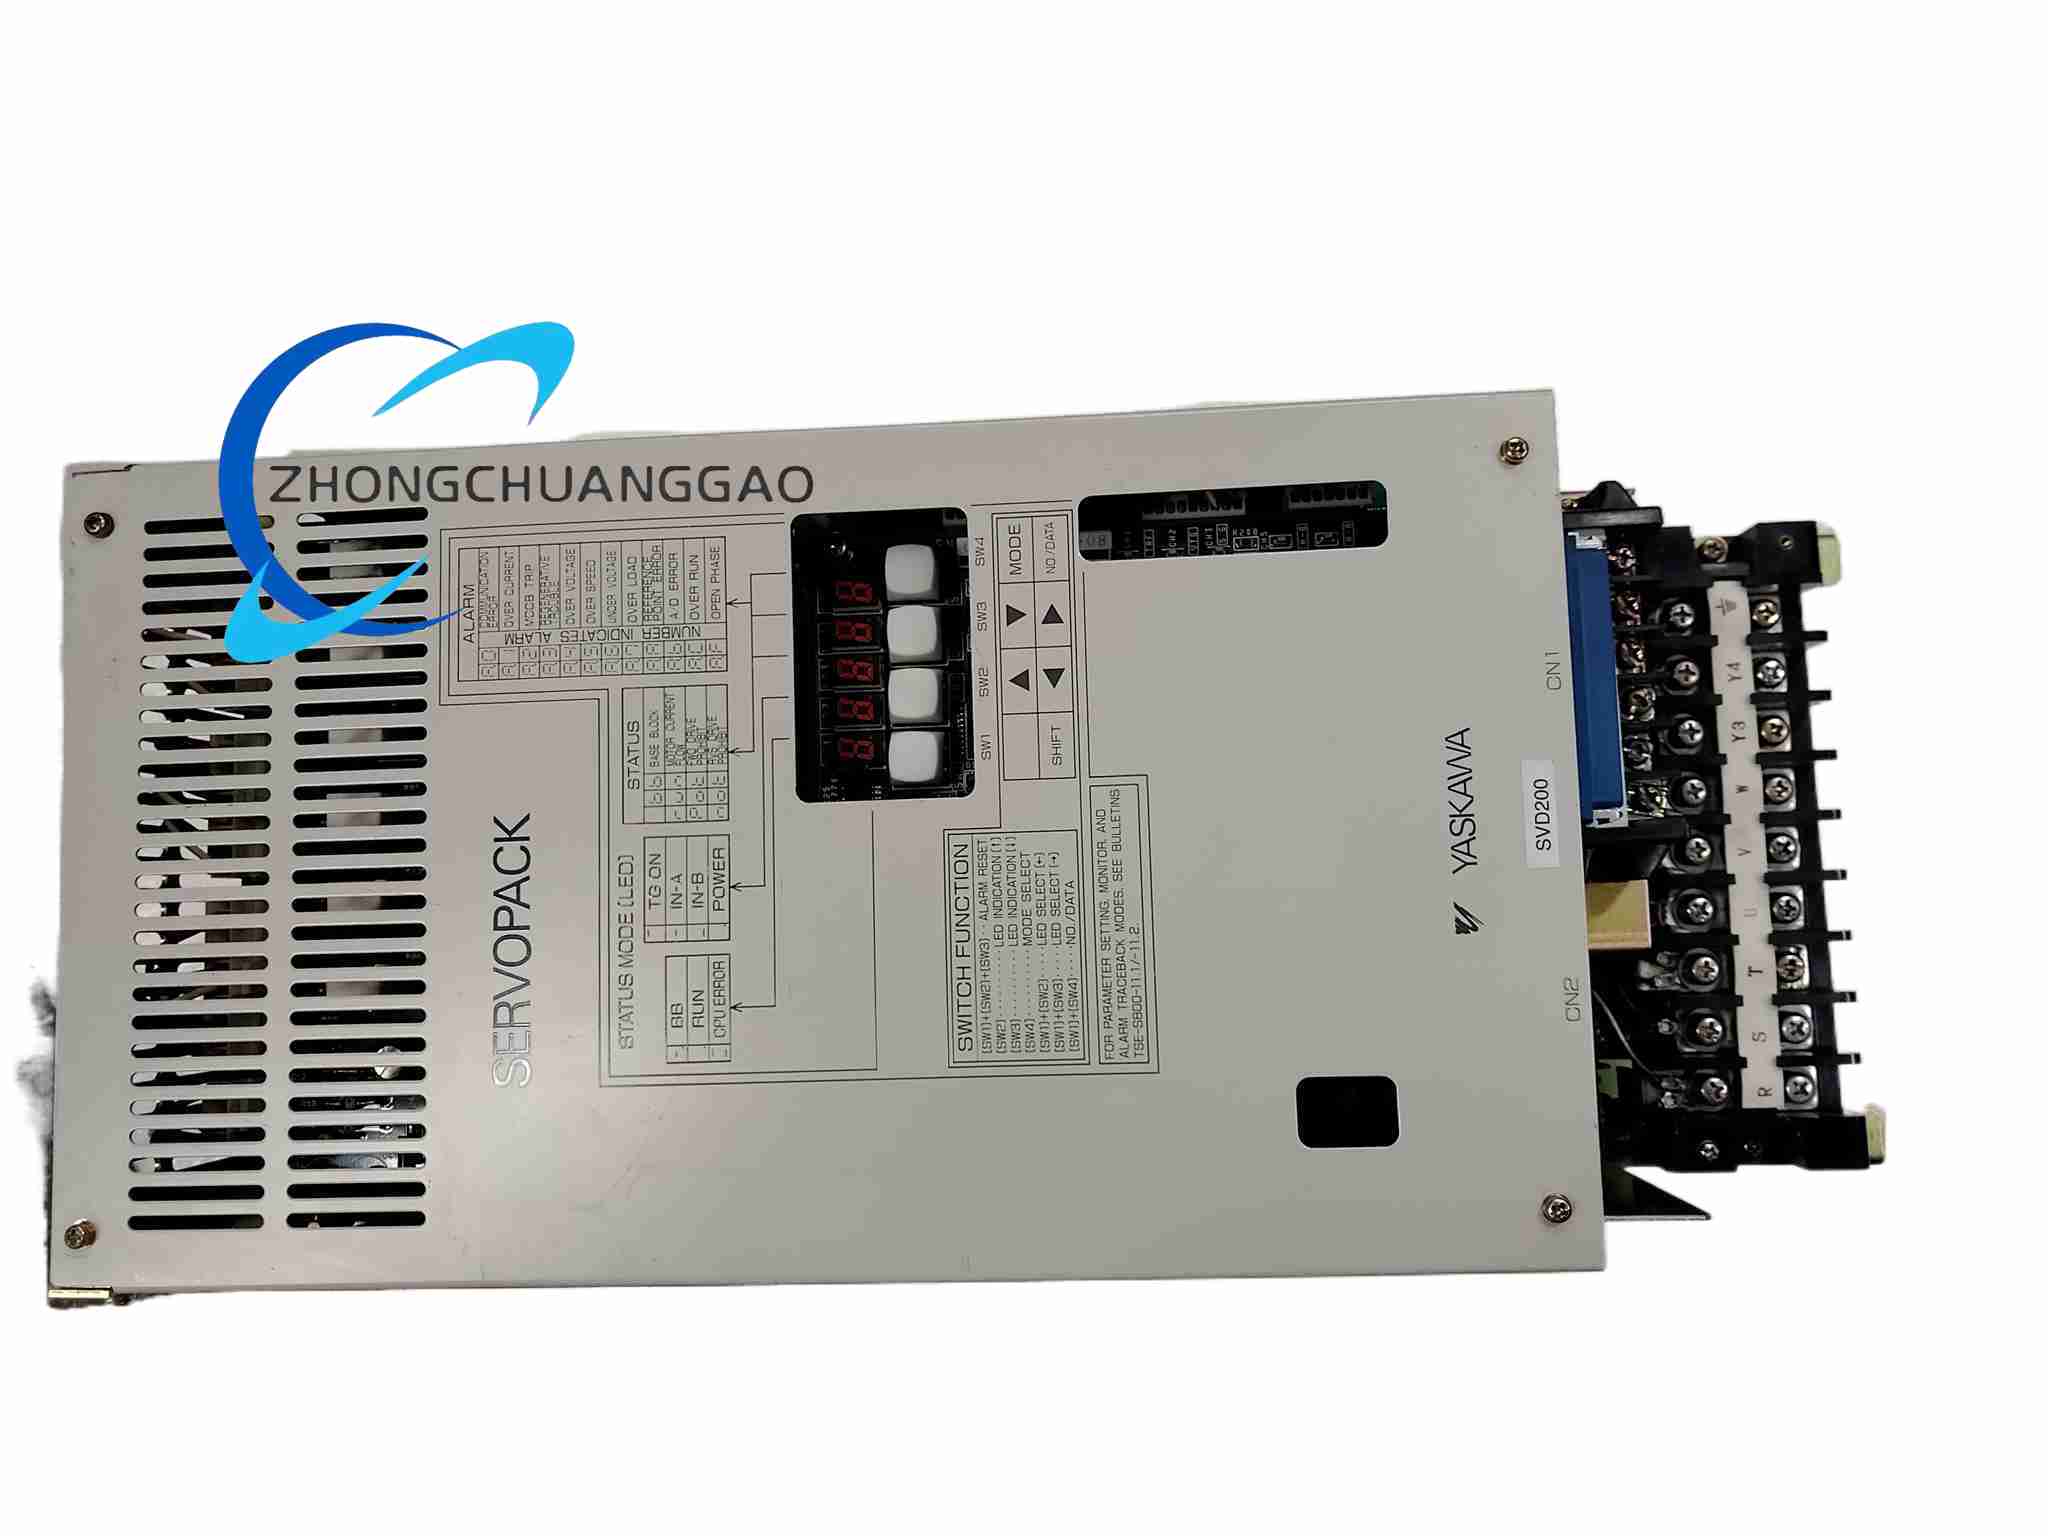
Operator Panel: LED display for parameters, alarms and tuning data
Protection Suite: Overcurrent, overvoltage, undervoltage, overload and motor overtemperature
Parameter Copy: Settings transfer between drives where supported
Application Scenarios: CNC feed axes, packaging forming stations, printing auxiliary drives, assembly machines, indexing conveyors and general automation retrofit projects.
Performance Parameters:
Positioning Accuracy: Determined by encoder resolution and pulse command source
Speed Bandwidth: 1 kHz servo response
Torque Stability: Closed-loop current regulation with encoder feedback
Material Composition:
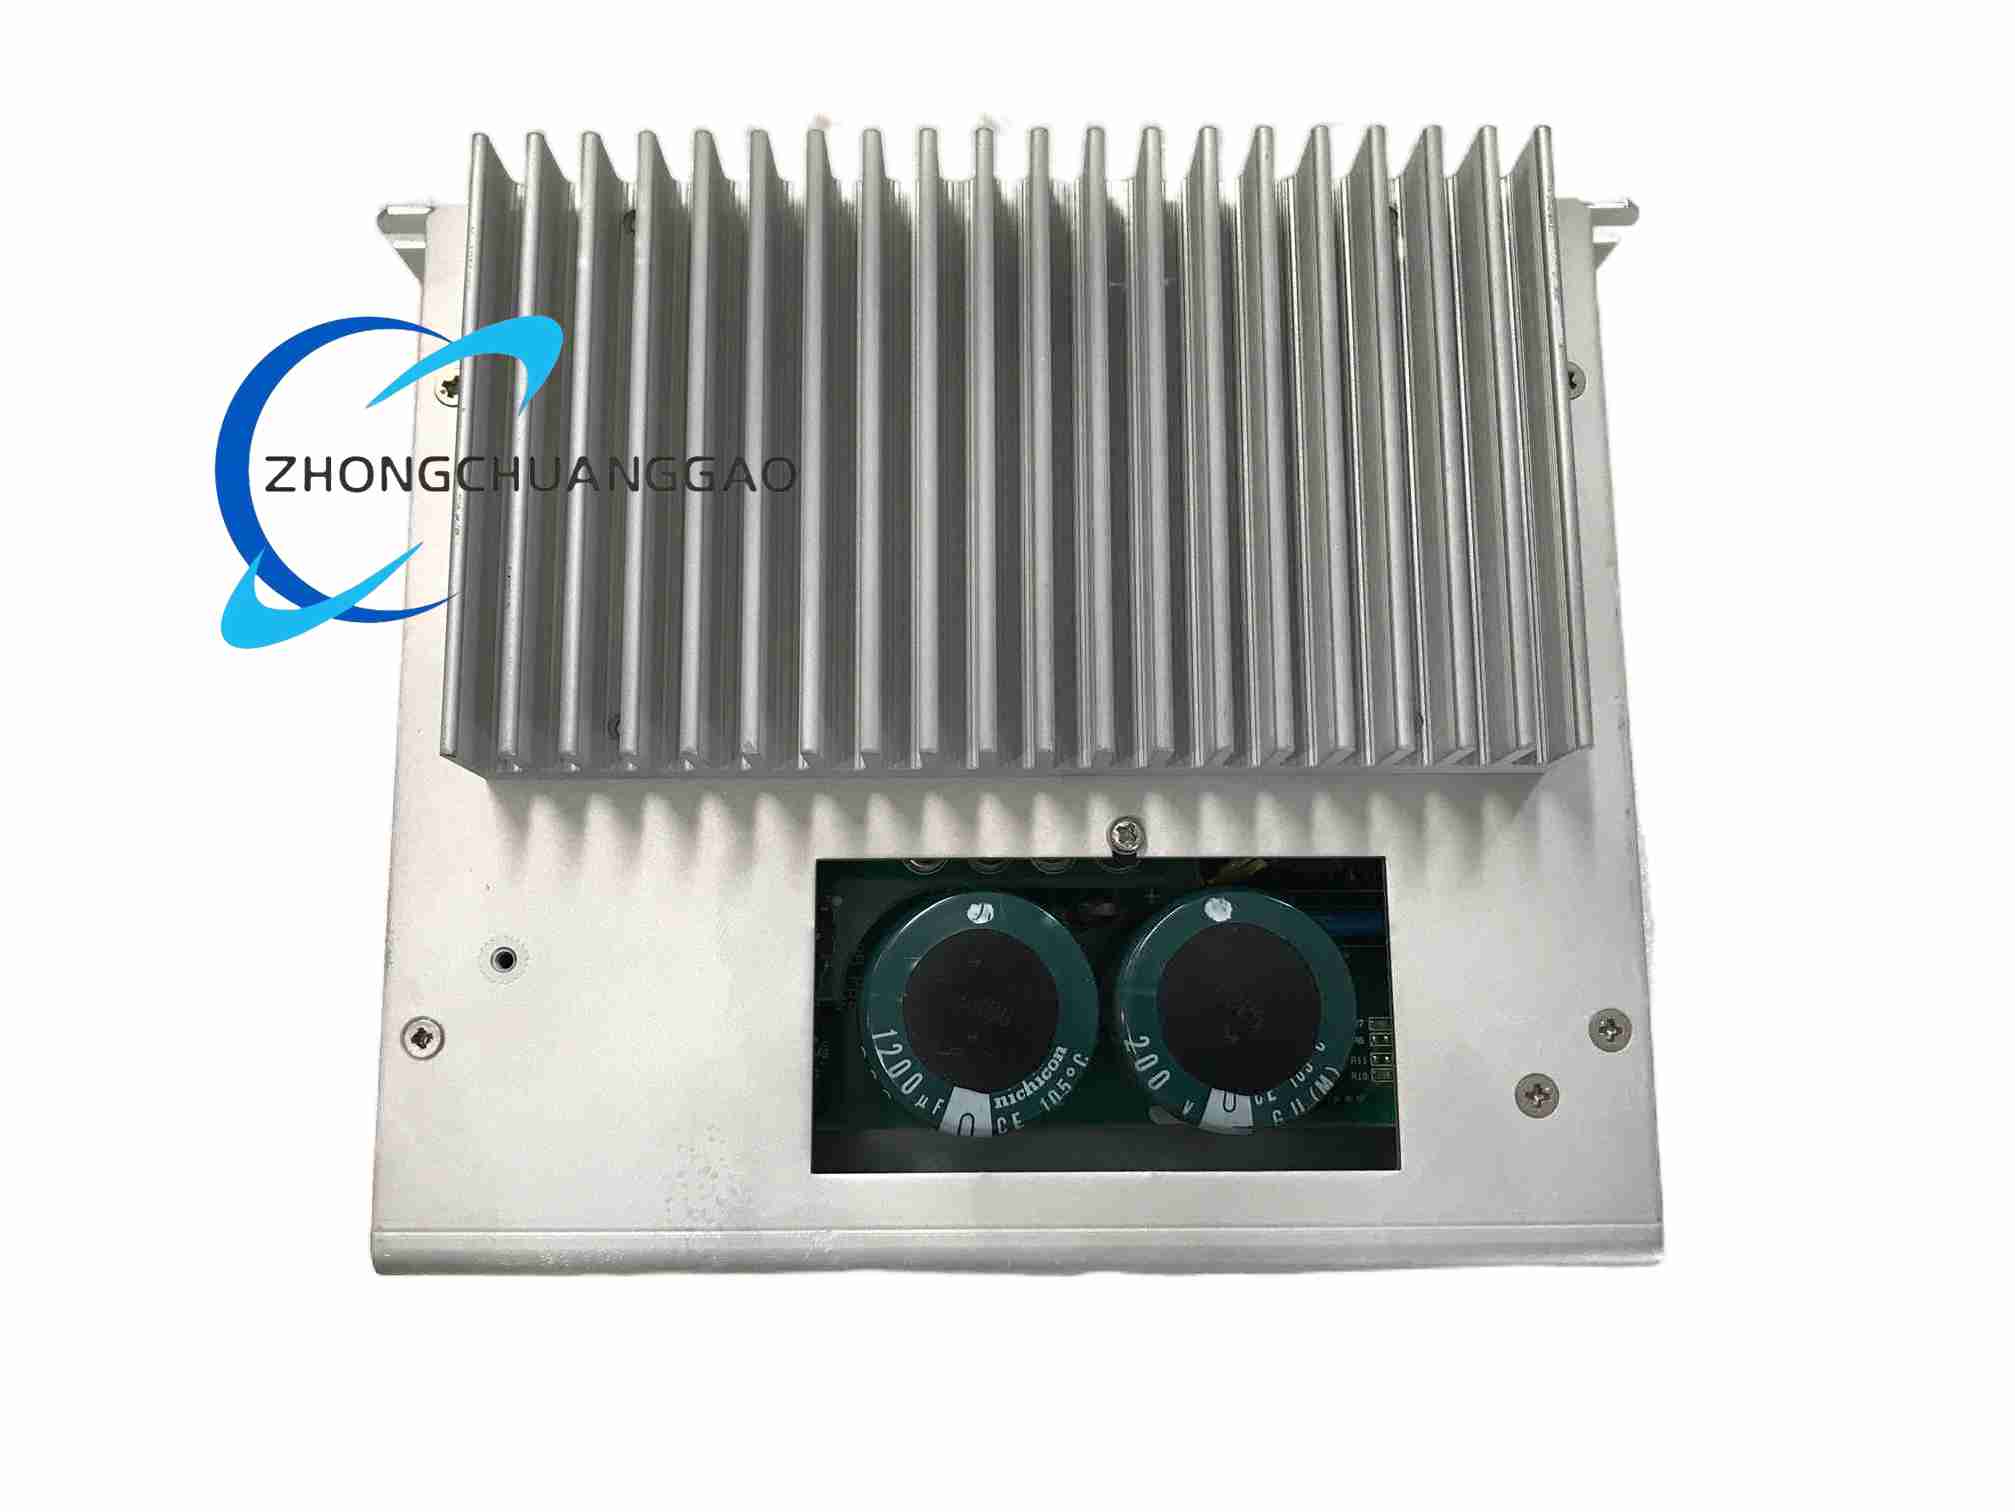
Housing: Aluminum heatsink enclosure
Power Stage: IGBT PWM inverter module
Control Board: Industrial FR-4 with SMD components
Terminals: High-current insulated terminals with copper conductors
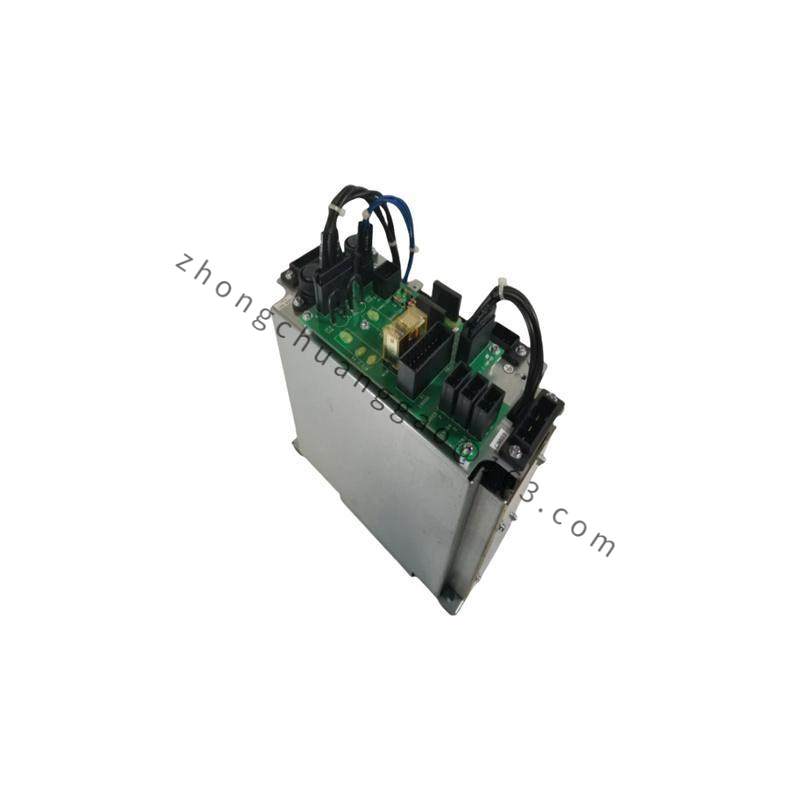
Structural Features: Book-style panel-mount body, front LED and keypad, pulse and analog I/O terminals, modular internal power section, separated signal and power wiring areas.
Working Principle: AC input is rectified to a DC bus and inverted into regulated three-phase output by the IGBT stage. The control board receives pulse or analog commands, calculates position, speed and torque setpoints, and corrects output using encoder feedback. Fault monitoring acts on current, voltage, temperature and encoder abnormalities.
Installation Requirements: Mount vertically in a control cabinet with top and bottom ventilation space. Supply three-phase 200 VAC to 230 VAC through a dedicated breaker. Separate motor power and encoder/signal cables. Ground the drive and shield encoder cables according to Yaskawa wiring rules.
Usage Notes: Use only with 1.5 kW class Yaskawa servo motors supported by the drive firmware. Complete autotuning or manual gain setting before load operation. Verify encoder wiring and pulse polarity before enabling position mode. Inspect cooling paths and terminal tightness periodically.