Technical Specifications
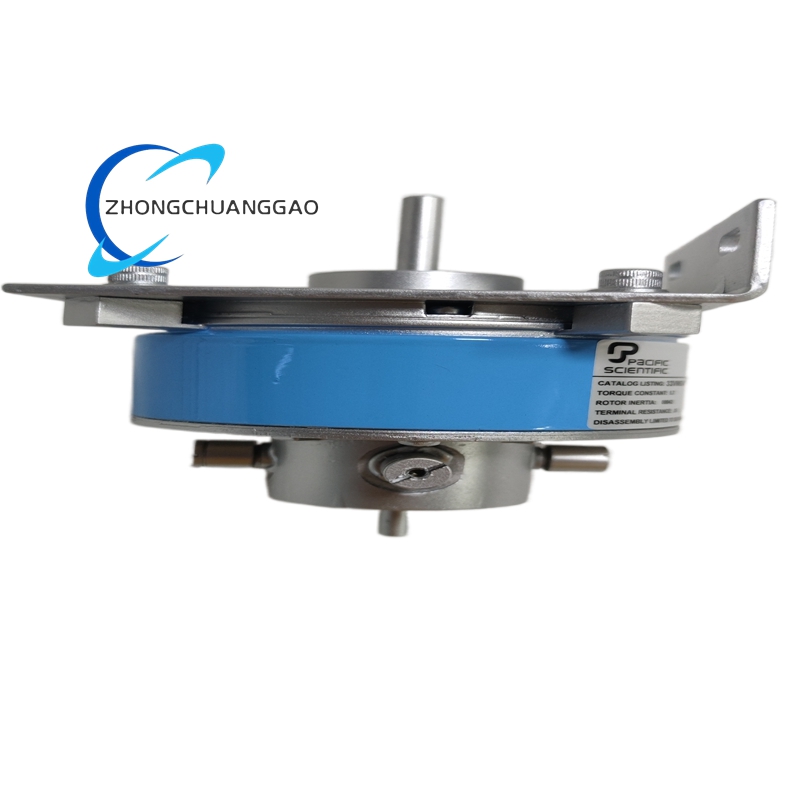
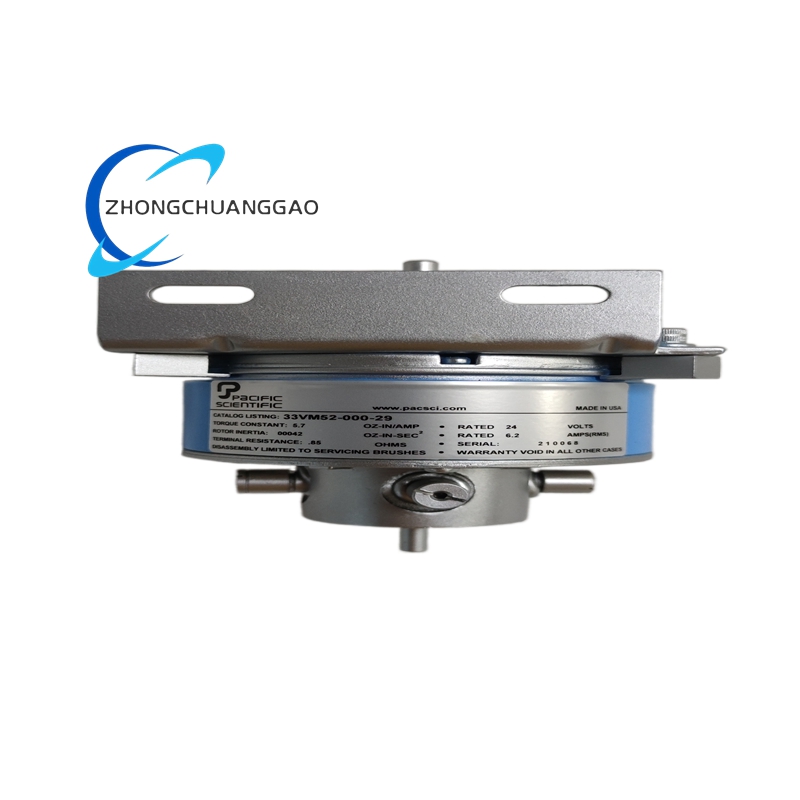
Operating voltage 18 to 36 VDC. Rated continuous current 3.1 to 5.7 A. Magnet material Alnico V-7. Drive-end bearing journal shaft diameter approximately 0.281 to 0.344 in. No forced-air cooling. No optical encoder. No analog tachometer. Position-sensing interface supported through external devices. Restricted rotational movement up to approximately 200 degrees in typical positioned configurations.
Functional Features
Low-inertia Alnico V-7 PMDC design. Three-wire connection scheme with black for ground, red for power and yellow or white for the control unit in documented VM actuator configurations. External position sensing for commanded angle or limited-travel actuation. Natural cooling without blower packages.
Application Scenarios
Valve or damper actuators, limited-angle positioning, test rigs, packaging mechanisms, auxiliary automation motions and replacement of legacy VM-series servo components where full rotary service is not required.
Performance Parameters
Continuous current range 3.1 to 5.7 A under the stated voltage class. Shaft motion can be configured for limited travel rather than continuous 360-degree rotation. Actual torque, speed and response depend on amplifier settings, feedback resolution and mechanical load.
Material and Structure
Alnico V-7 permanent magnets. DC armature with commutator. Journal shaft in the stated diameter range. Standard VM housing without factory encoder or tachometer. Actuator variant uses control, power and ground wiring according to the supplied harness notation.
Working Principle
The control unit sends a command signal to the servo amplifier or actuator interface. The amplifier drives armature current through the PMDC motor. The magnetic field interaction produces torque, and the position-sensing element reports shaft angle so the controller can stop, hold or reverse the output within the allowed travel range.
Installation Requirements
Verify voltage class 18 to 36 VDC and amplifier current capability 3.1 to 5.7 A. Use the correct black, red and yellow or white wiring assignment from the motor nameplate. Mechanically limit travel if the application requires less than the approximately 200-degree range. Mount the load so side loads do not exceed the journal bearing specification.
Usage Precautions
This model is not supplied with an onboard encoder or analog tachometer; use external feedback for precision control. Do not force continuous full-rotation service if the actuator is configured for limited-angle operation. Prevent overheating by respecting duty cycle and ambient limits. Check commutator, brushes and wiring insulation before commissioning older units.