Technical Specifications
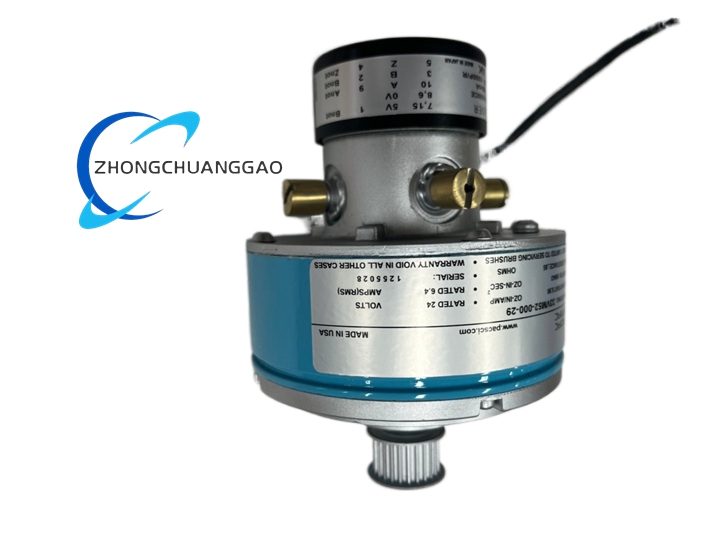
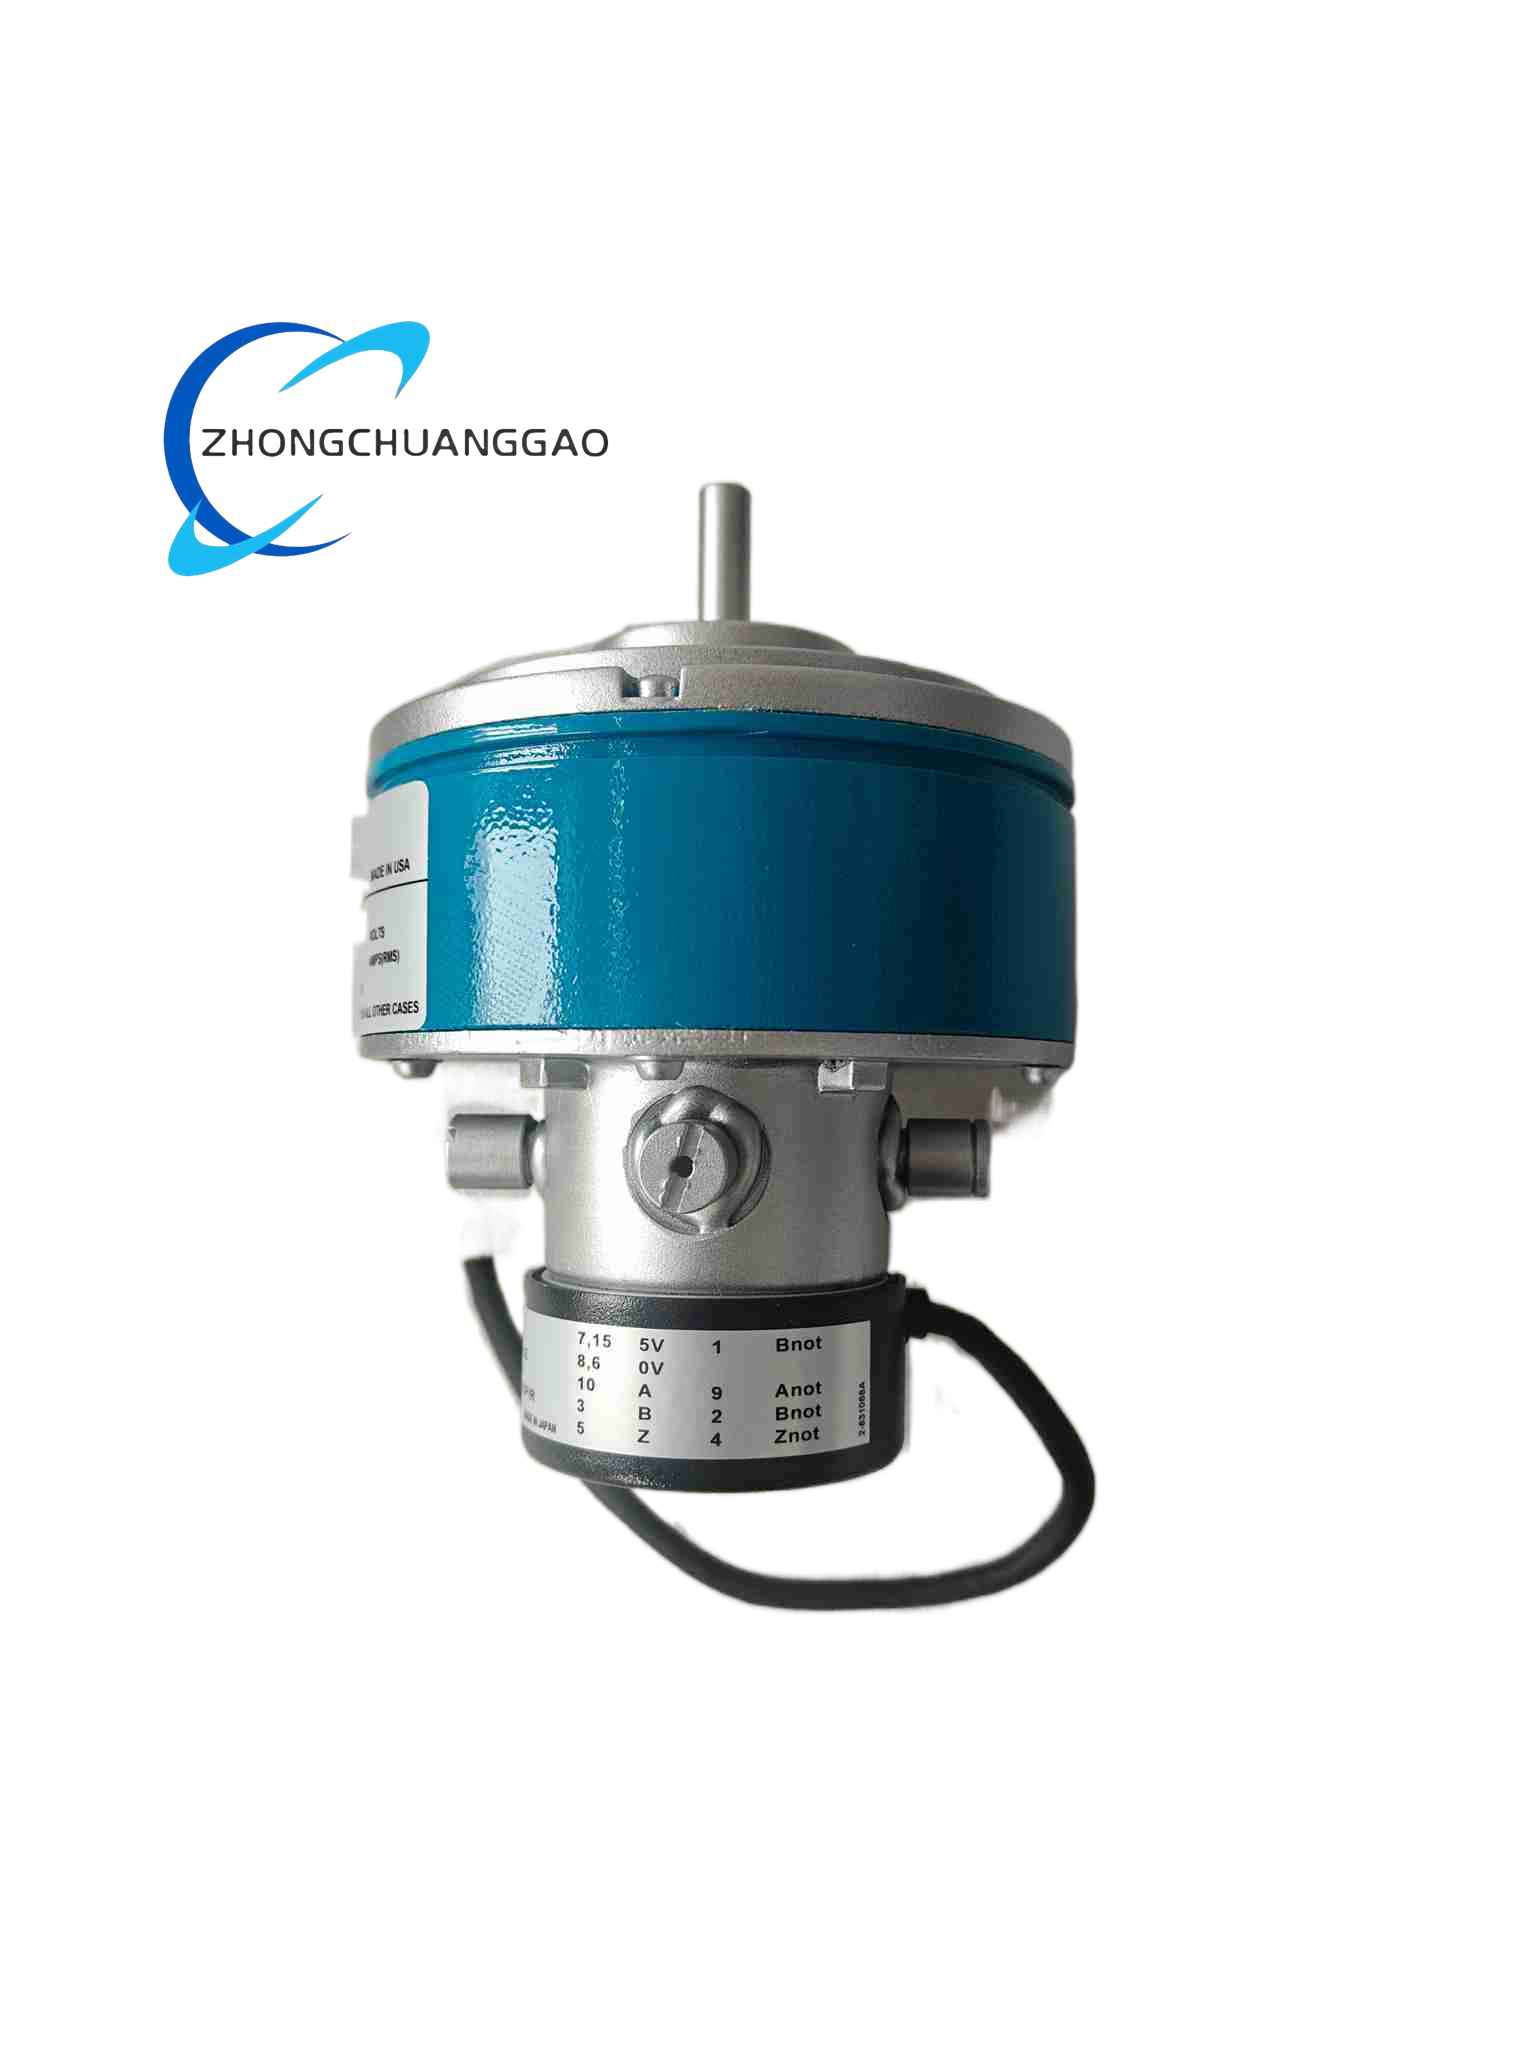
Rated voltage 24 VDC. Operating voltage range 18 to 36 VDC. Rated current approximately 6.4 A. Rotor inertia approximately 0.00043 oz-in-sec². Torque constant approximately 5.9 oz-in/A. Terminal resistance approximately 0.85 Ω. Magnet material Alnico V-7. Shaft journal diameter approximately 0.281 to 0.344 in. No attached optical encoder. No attached analog tachometer. No forced-air cooling.
Functional Features
Low-inertia rotor for rapid start-stop cycles. Permanent-magnet field with Alnico V-7 magnets. Natural convection cooling. Compatible with external servo drives, encoders and tachometers when the control system requires closed-loop feedback.
Application Scenarios
Packaging machines, CNC auxiliary axes, robotics retrofits, material handling, indexing tables, printing equipment and legacy motion systems where the original VM motor characteristics must be preserved.
Performance Parameters
Continuous performance depends on amplifier current limit, duty cycle and heat dissipation. The 24 VDC rating with approximately 6.4 A provides moderate torque for small-axis positioning. Low inertia supports high acceleration but requires correct servo gain tuning.
Material and Structure
Permanent-magnet stator using Alnico V-7. Commutator DC armature. Shaft journal in the stated diameter range. housing designed for flange or machine mounting. Standard motor construction without factory-installed encoder or tachometer.
Working Principle
DC current in the armature winding interacts with the permanent-magnet field to produce torque. The commutator switches current to maintain rotation direction. An external servo amplifier regulates armature current based on the commanded position or speed, using externally mounted feedback if required.
Installation Requirements
Match the servo amplifier to the 18 to 36 VDC range, 6.4 A class current and 0.85 Ω armature resistance. Align the shaft and coupling without side-loading the bearing. If feedback is needed, mount a compatible encoder or resolver to the optional feedback interface. Verify mounting flange and shaft dimensions before replacement.
Usage Precautions
This standard configuration does not include an onboard encoder or tachometer; do not assume closed-loop capability without external feedback. Avoid continuous overload that exceeds the amplifier and motor thermal limits. Inspect brushes and commutator periodically. Confirm magnet and winding condition before returning older units to service.