Technical Specifications:
Main Power: 3-phase 400 VAC to 480 VAC, 50/60 Hz according to drive configuration
Control Supply: 24 VDC
Synchronous Axes: Up to 10 axes
Rated Amplifier Output: 1 kW class, 10 A nominal
Peak Current: 25 A for short-duty intervals
Position Accuracy: ±0.001 mm in configured servo systems
Speed Accuracy: ±0.01%
Torque Accuracy: ±0.1%
Response Frequency: 500 Hz servo loop bandwidth
Communication Interfaces: SERCOS III, EtherCAT, CANopen, PROFINET IRT
Safety Functions: STO integrated, SS1 and SOS supported
Programming: IEC 61131-3, PLCopen Motion Parts 1 and 2, optional G-code
Memory: 512 MB RAM, 1 GB flash, expandable
Operating Temperature: 0°C to 55°C with derating
Protection Rating: IP20
Mounting: DIN rail or panel mounting; rack-format configurations available
Functional Features:
Motion Functions: Electronic cam, electronic gear, flying shear, interpolation and multi-axis path planning
Recipe Management: Fast format change without mechanical adjustments
Diagnostics: Event logging, axis alarms, communication diagnostics
Scalability: Remote I/O and additional servo nodes through SERCOS III, EtherCAT or CANopen
Application Scenarios: High-speed cartoners, fillers, flow wrappers, labelers, printing presses, robotic pick-and-place cells, plastic extrusion lines and pharmaceutical packaging systems.
Performance Parameters:
Trajectory Cycle: Millisecond-level planning for synchronized axes
Servo Bandwidth: 500 Hz typical current/speed/position tuning
Bus Performance: Deterministic servo communication with low jitter
Material Composition:
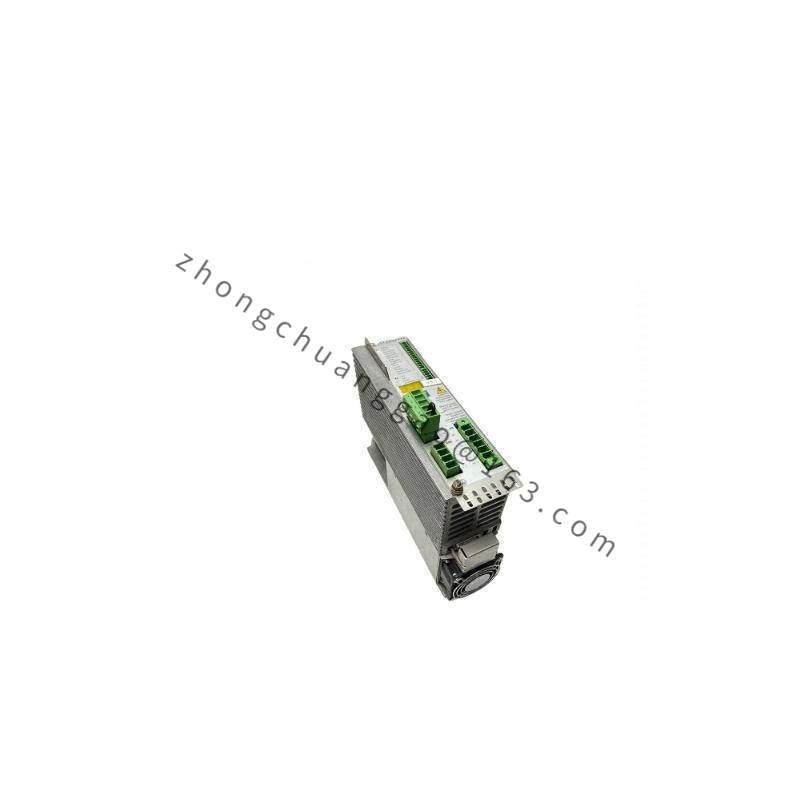
Chassis: Metal industrial enclosure
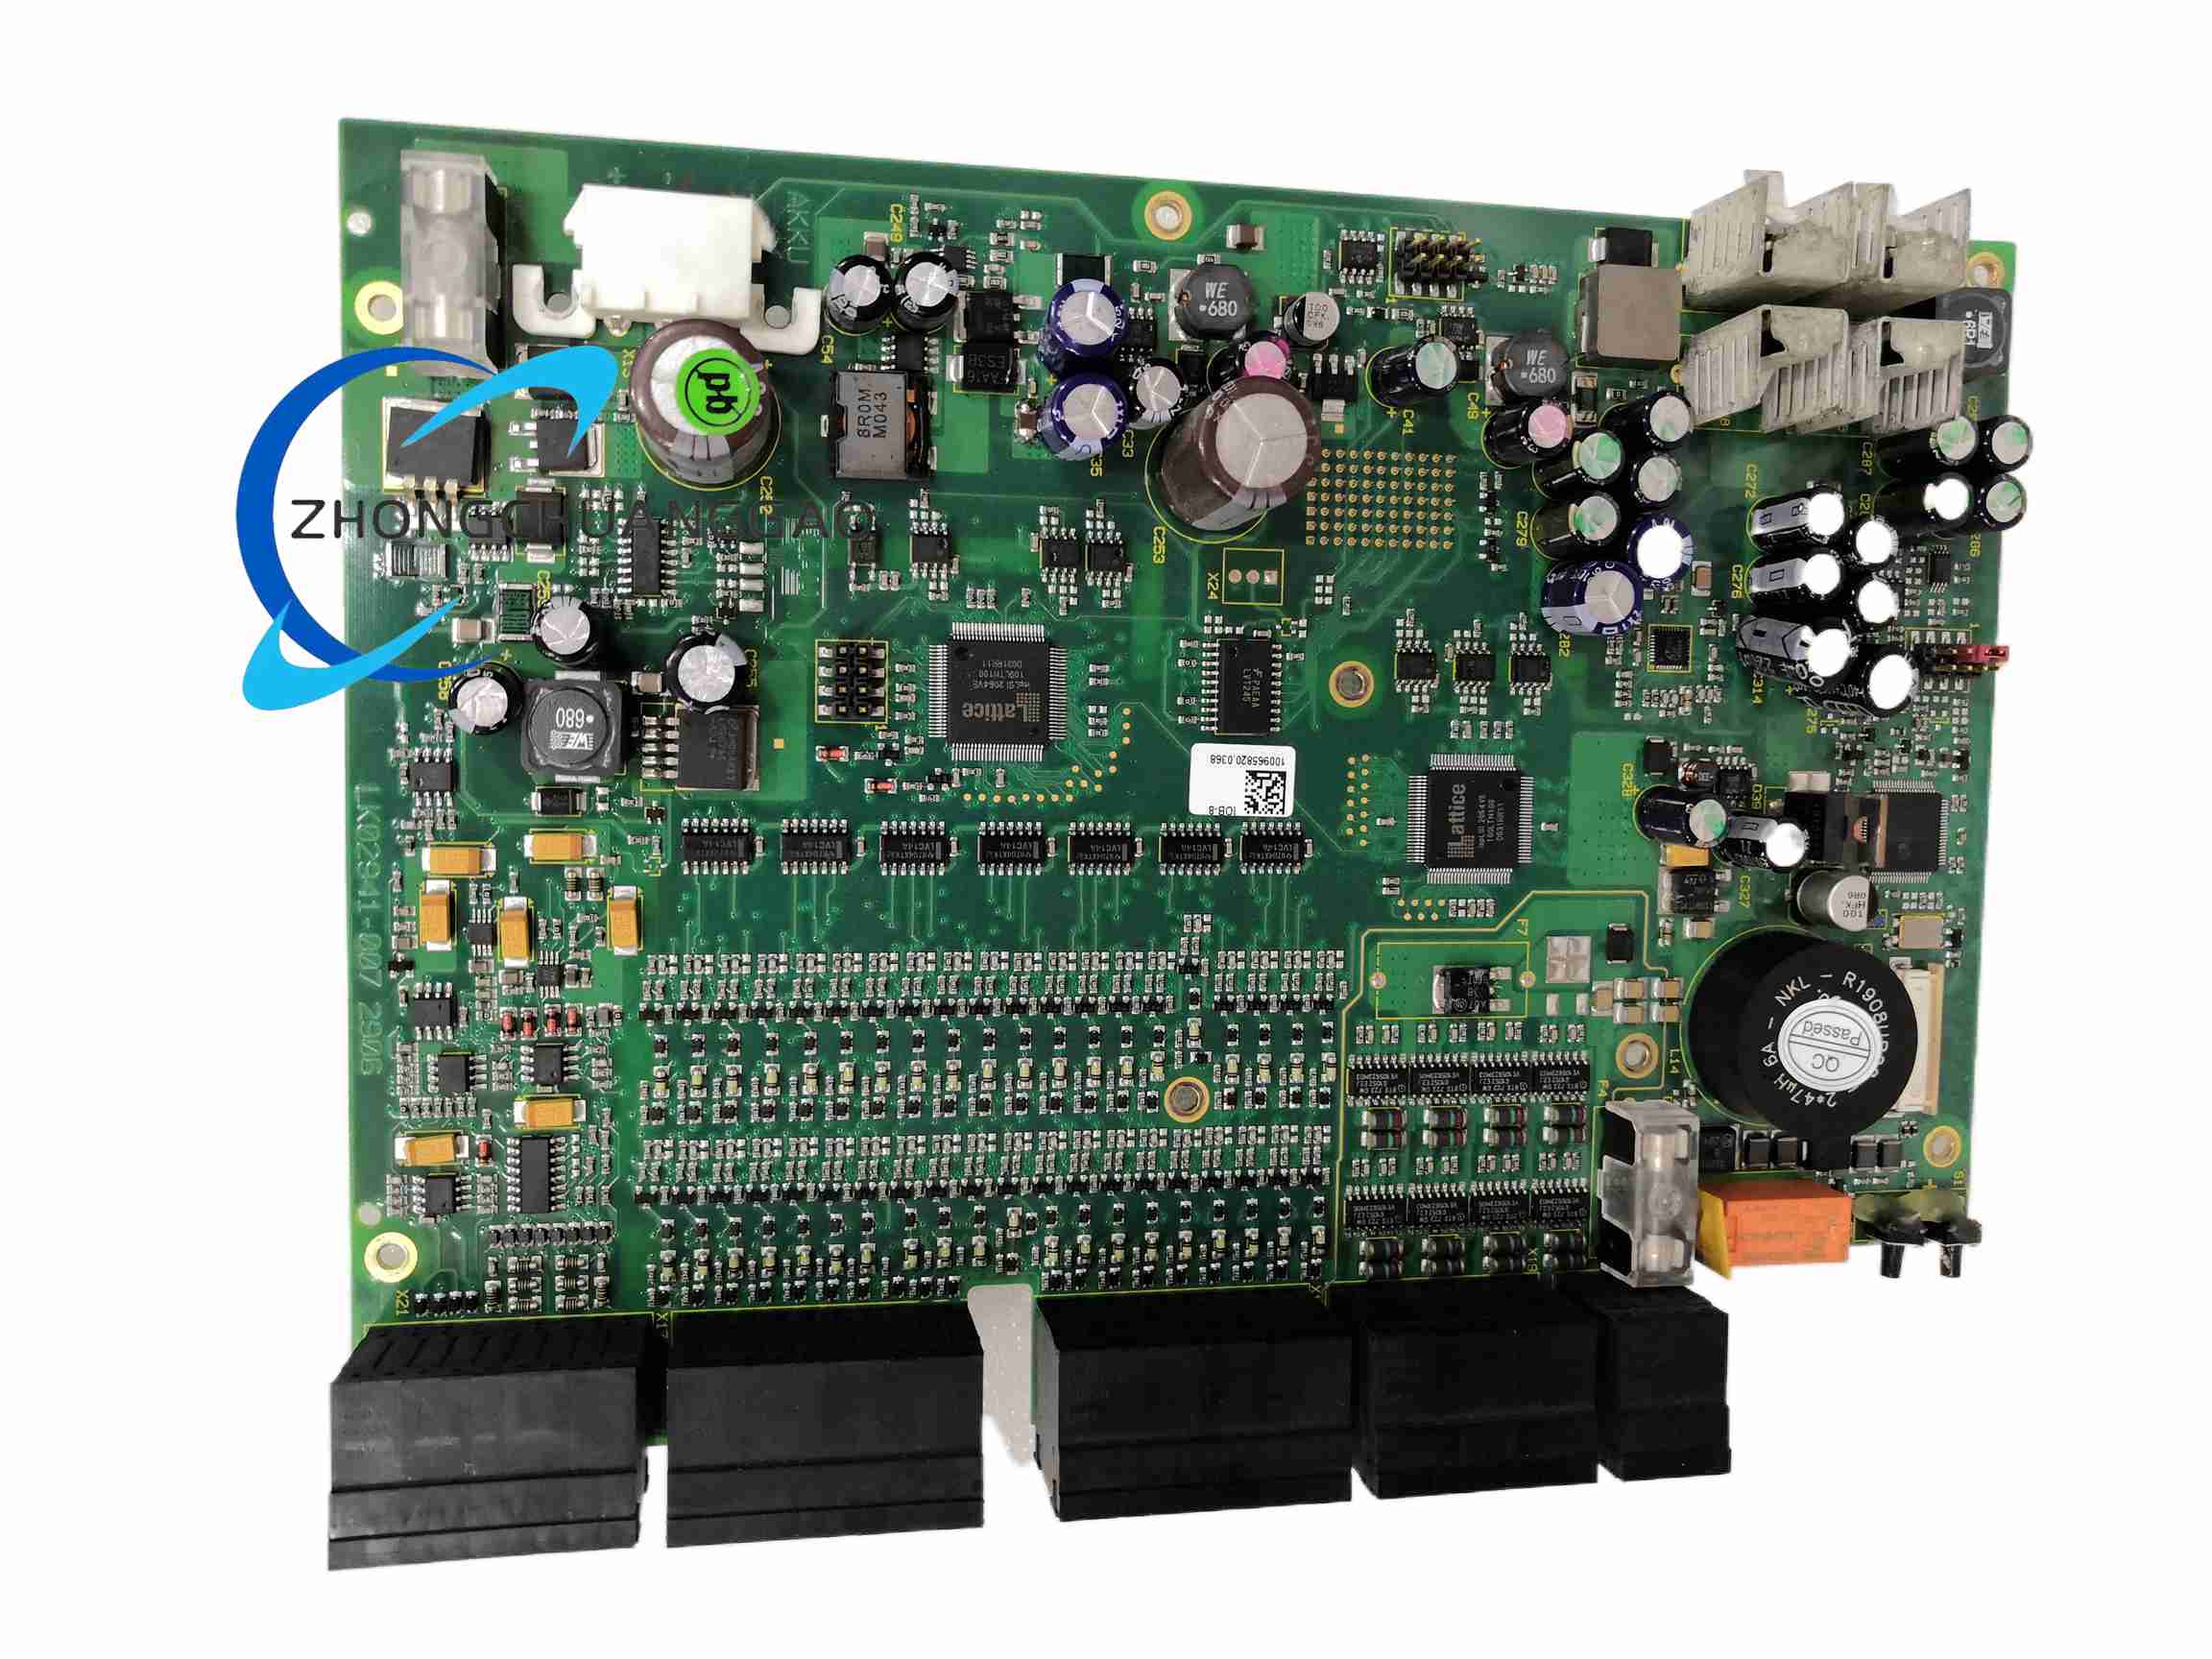
PCB: Multilayer FR-4 with industrial components
Cooling Parts: Passive heatsink or forced ventilation according to power section
Connectors: Shielded SERCOS, EtherCAT, CANopen and Ethernet interfaces
Structural Features: Compact book or modular cabinet body, front LEDs, service Ethernet and serial ports, separated power, motor and signal compartments.
Working Principle: The controller executes logic and motion applications in a real-time environment. It generates per-axis position, speed and torque commands and transmits them over the selected servo bus. Drive feedback returns actual position and status, enabling closed-loop correction. Safety circuitry monitors enable signals and initiates STO, SS1 or SOS when triggered.
Installation Requirements: Mount in a ventilated cabinet with adequate spacing for convection or forced cooling. Connect 3-phase main power through properly rated breakers. Provide isolated 24 VDC control supply. Install SERCOS, EtherCAT, CANopen or PROFINET cables with correct topology and termination. Ground the cabinet and shield cables according to EMC rules.
Usage Notes: Perform axis autotuning under no-load conditions before production. Validate safety functions with documented tests. Avoid exceeding 55°C ambient without derating. Keep firmware, project backup and drive parameter files consistent.