Technical Specifications
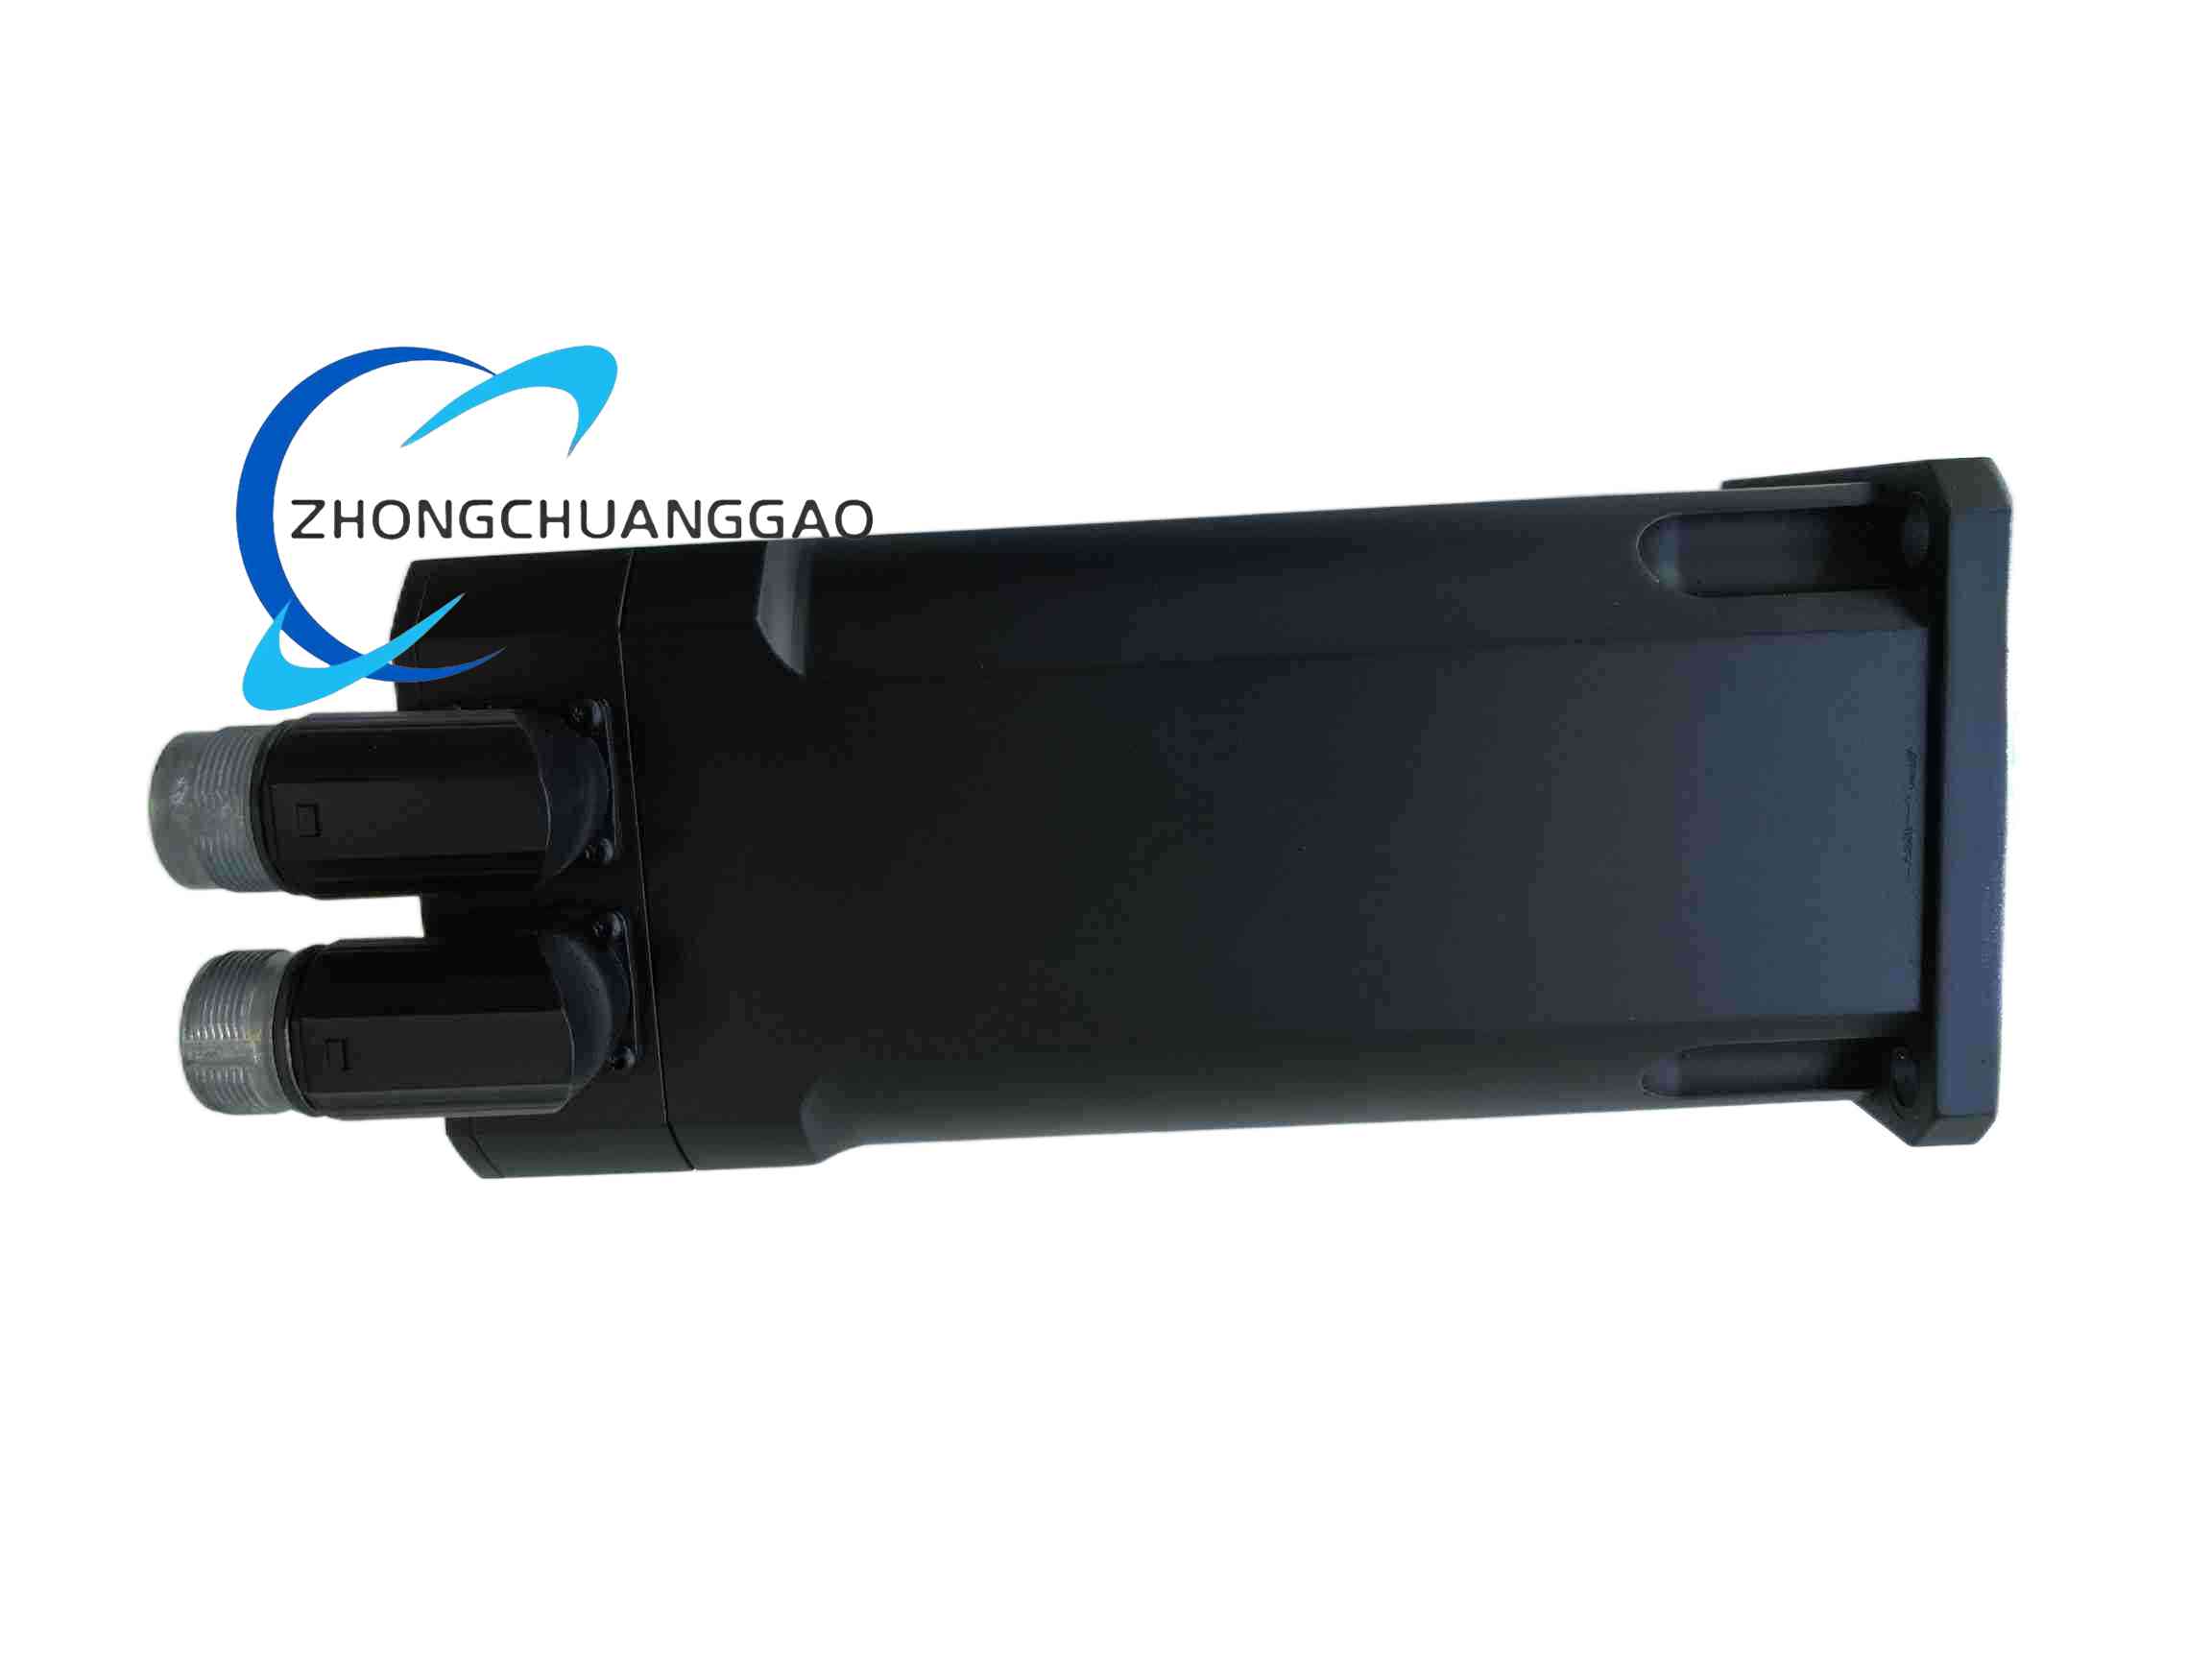
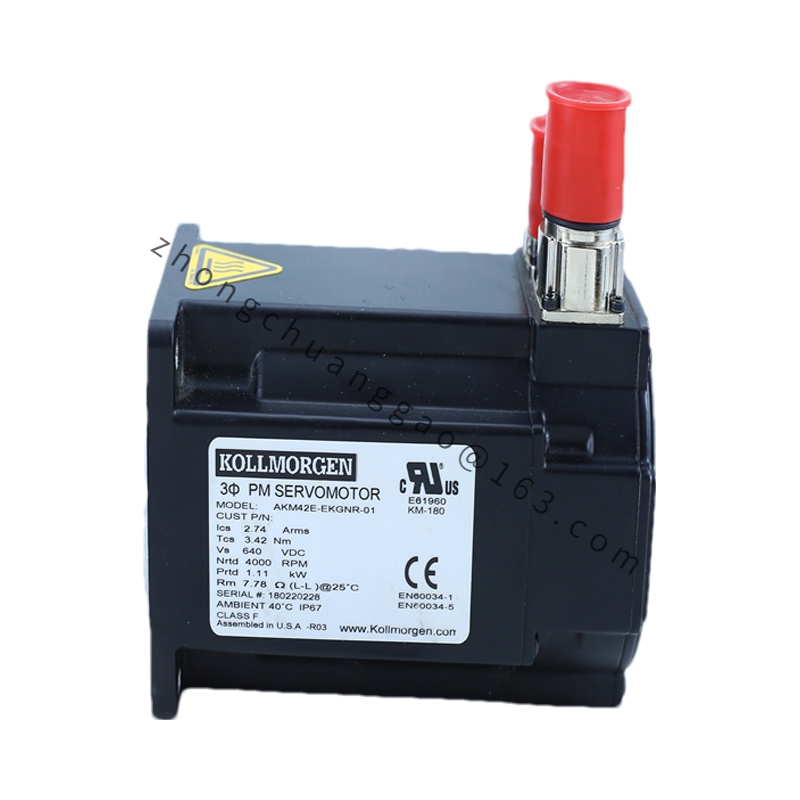
Frame: 57 x 57 mm square flange.
Rated power: approximately 1.4 kW.
Rated speed: 3000 rpm.
Rated torque: 3.0 Nm.
Standstill torque: 3.0 Nm.
Peak torque: 9.0 Nm subject to drive current limit.
Rated current: 4.3 A RMS.
Standstill current: 2.3 A RMS.
Peak current: 11 A RMS.
Torque constant: 1.65 Nm/A line-to-line.
Voltage constant: 97 mV/min referenced to back EMF.
Winding resistance: 6.3 ohm line-to-line.
Winding inductance: 35 mH line-to-line.
Rotor inertia: 0.42 x 10^-4 kg·m².
Insulation class: F, 155 °C.
Protection class: IP65.
Shaft: 14 mm keyed, smooth optional.
Radial shaft load: 150 N maximum at shaft end.
Axial shaft load: 90 N maximum.
Feedback: resolver standard, incremental encoder optional.
Brake: 24 V DC spring-applied disc brake optional.
Weight: approximately 3.8 kg without brake, 4.5 kg with brake.
Functional Features
High continuous torque relative to 57 mm frame size.
Low cogging for smooth low-speed motion.
Resolver or encoder feedback for position and speed control.
Optional holding brake for vertical or retained-load axes.
Rugged IP65 housing for industrial environments.
Application Scenarios
Conveyors, material handling, robotic joints, index tables, CNC auxiliary axes, packaging machines and moderate-torque positioning systems.
Performance Parameters
3 Nm continuous at 3000 rpm with 9 Nm peak for acceleration.
Fast current response governed by winding inductance and drive bandwidth.
Thermal time constant approximately 20 minutes winding, 45 minutes housing.
Material And Structure
Cast-aluminum IP65 housing.
Neodymium-iron-boron rotor magnets.
Precision bearings, keyed shaft and resolver/encoder compartment.
Terminal or connector power and feedback interface according to suffix.
Working Principle
Three-phase sinusoidal current creates a rotating stator field. The permanent-magnet rotor follows the field. Resolver or encoder feedback provides position/speed data to the servo amplifier, which adjusts current to maintain the commanded trajectory.
Installation Requirements
Mount on IEC or Kollmorgen 57 mm square flange.
Align keyed shaft with coupling and avoid excessive shaft loads.
Separate shielded power cables and shielded resolver/encoder twisted pairs.
Connect thermal sensor to drive protection input where fitted.
Supply 24 V DC brake release voltage only when brake option is installed.
Usage Precautions
Operate within 0 to 40 °C ambient unless formally derated.
Do not exceed 150 N radial and 90 N axial shaft loads.
Size servo amplifier for 9 Nm peak without sustained overheating.
Ensure brake is released before motion; loss of brake voltage re-engages holding brake.