Technical Specifications
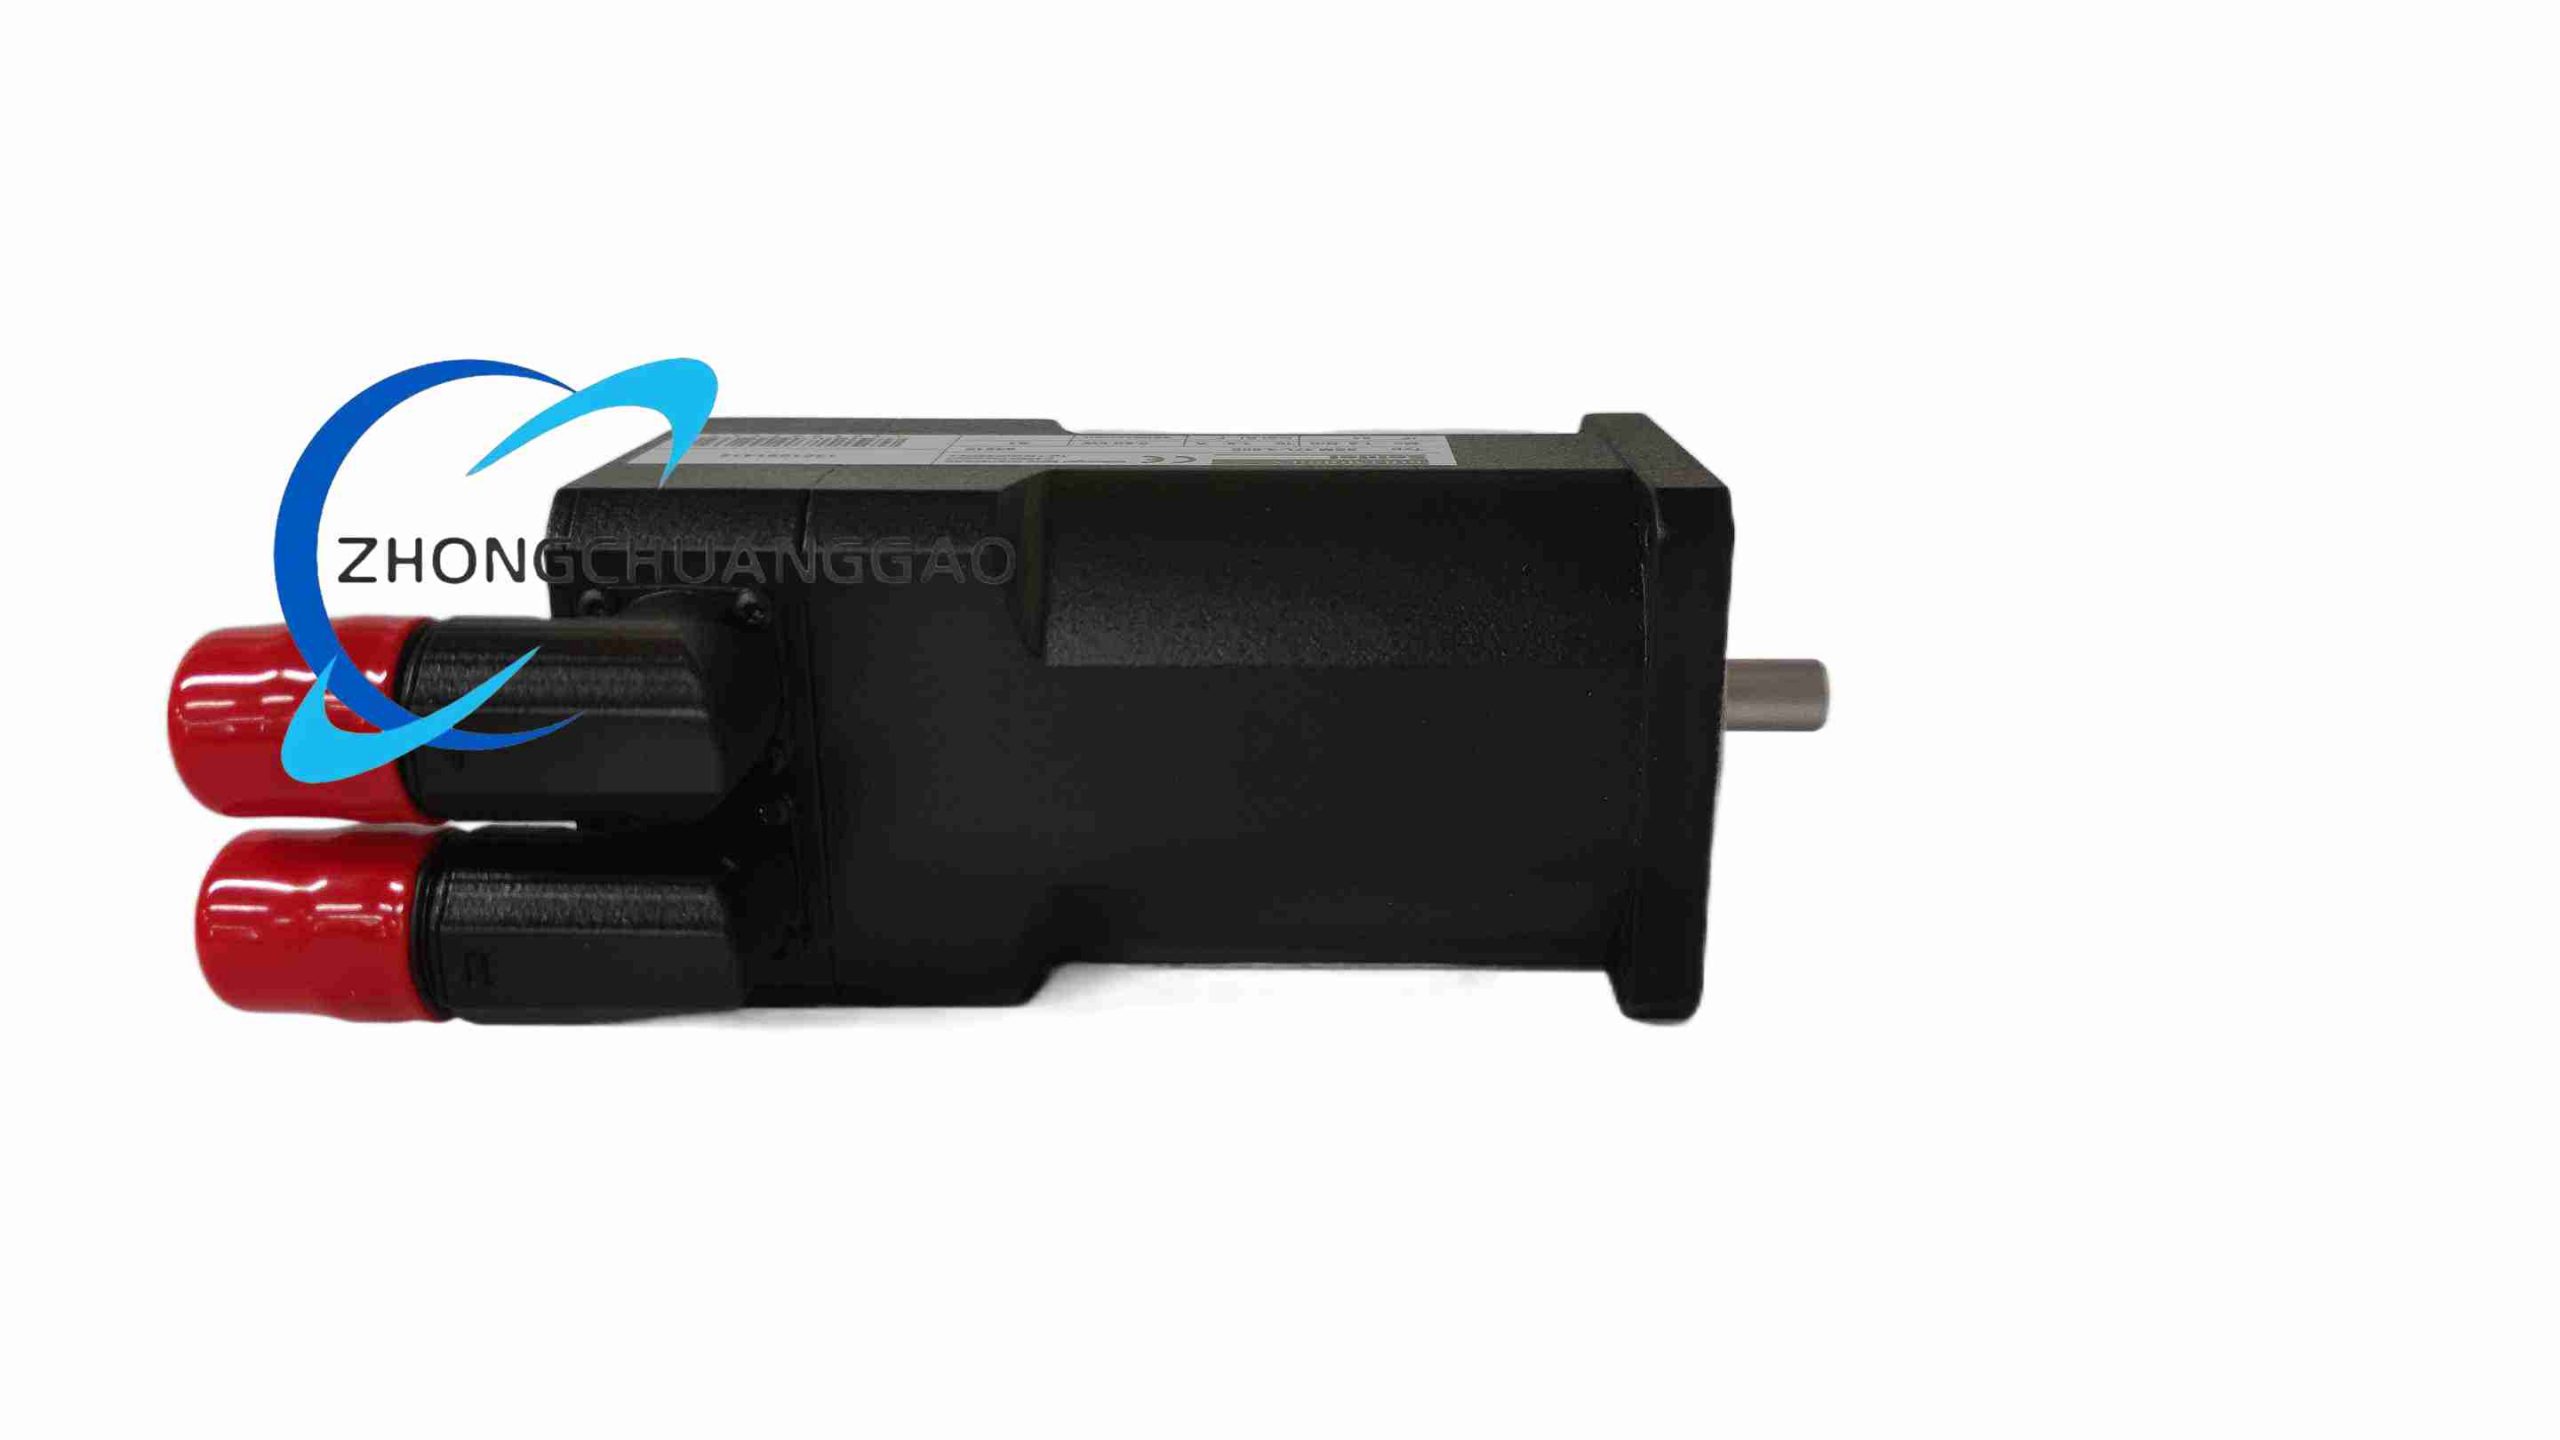
Rated power: approximately 1.5 kW per available distributor datasheet for 6SM 37L-4.000.
Rated speed: 3000 rpm, maximum speed listed up to 6000 rpm in some configurations.
Rated torque: approximately 4.5 Nm.
Peak torque: approximately 15.2 Nm.
Rated current: approximately 4.0 A.
Rotor inertia: approximately 0.000137 kg·m².
Feedback: absolute encoder option per configuration.
Mounting flange: approximately 80 x 80 mm according to listed 6SM 37L data.
Functional Features
Low-inertia rotor for fast dynamic response.
Brushless construction reduces maintenance.
High torque density for compact automation axes.
Compatible with Kollmorgen servo drives and selected third-party amplifiers.
Application Scenarios
CNC feed axes, robotics, indexing tables, packaging machines, semiconductor handling, material handling and high-response positioning systems.
Performance Parameters
Smooth sinusoidal commutation with resolver, incremental encoder or absolute encoder depending on ordered feedback.
High peak-to-continuous torque ratio for acceleration duty.
Low cogging designs improve low-speed stability in selected 6SM variants.
Material And Structure
Aluminum or cast alloy motor housing.
Rare-earth permanent-magnet rotor.
Precision bearings, keyed or smooth shaft according to suffix.
Rear feedback compartment for encoder/resolver.
Working Principle
The servo drive supplies controlled three-phase current to the stator. The rotating magnetic field interacts with the permanent-magnet rotor. Feedback sends position and speed signals to the drive, which closes the control loop.
Installation Requirements
Flange-mount on matched 80 mm or specified frame pattern.
Align shaft with flexible coupling to avoid radial and axial overload.
Use shielded power and feedback cables in separate cable paths.
Ground the motor frame and drive chassis.
Usage Precautions
Verify rated torque, peak torque and thermal limits before continuous duty.
Do not exceed shaft radial and axial load ratings.
Check encoder resolution and wiring with the servo drive before startup.
Prevent condensation, excess vibration and overheating above nameplate limits.