Technical Specifications
Standard interface version supports CAN 2.0A, CAN 2.0B, and selected variants support CAN-FD. Operating voltage is 9 to 30 VDC. Classic CAN data rate reaches 1 Mbps. Isolated transceiver interface follows ISO 11898. Connectors are DB9, screw terminal, or spring-cage terminal depending on variant. Operating temperature is -40 to +85°C for rugged interface versions and -20 to +65°C for motor-control versions.
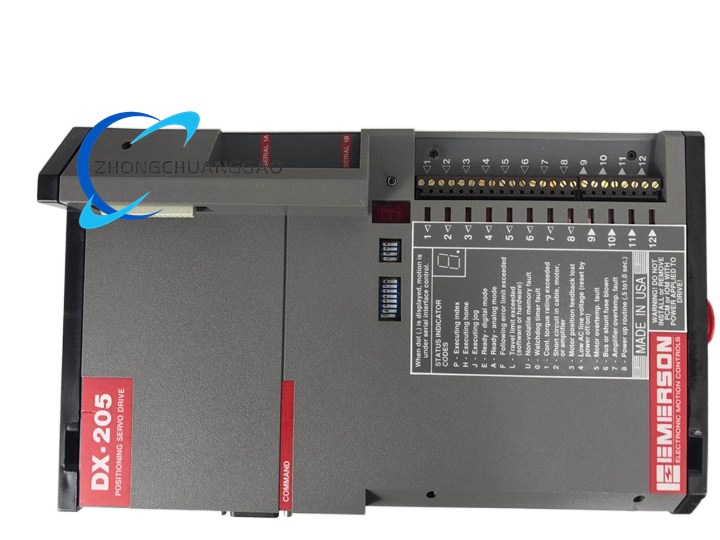
Motor-control version operates from 24 VDC control power. Galvanic isolation between bus circuit and control circuit reaches 2000 VAC. Analog command output is 0 to 10 V for external DC-drive reference. CAN baud rate, node ID, and termination are set by DIP switch or software.
Function Features
Automatic CAN node configuration, LED status for power, communication, and fault, integrated termination resistors, galvanic isolation, and real-time parameter exchange. Motor version adds torque or speed closed-loop command conversion, current feedback acquisition, and bus-side diagnostics.
Application Scenarios
Factory automation networks, packaging machines, conveyor systems, brushed DC motor speed control, battery production lines, material handling, and distributed controller communication in electrically noisy environments.
Performance Parameters
Communication latency depends on baud rate and frame load. Classic CAN at 1 Mbps supports short-frame cycle times suitable for real-time I/O. Motor version provides linear 0 to 10 V output with feedback update cycles determined by CAN poll rate and DIP-configured node timing.
Material Composition
Housing uses UL94-V0 PA66 plastic, industrial ABS, or metal alloy depending on version. Internal isolation uses signal transformers or optocouplers. Terminals use tinned copper spring-cage or screw elements. Motor version includes an aluminum heat-conduction patch on the circuit board.
Structure Features
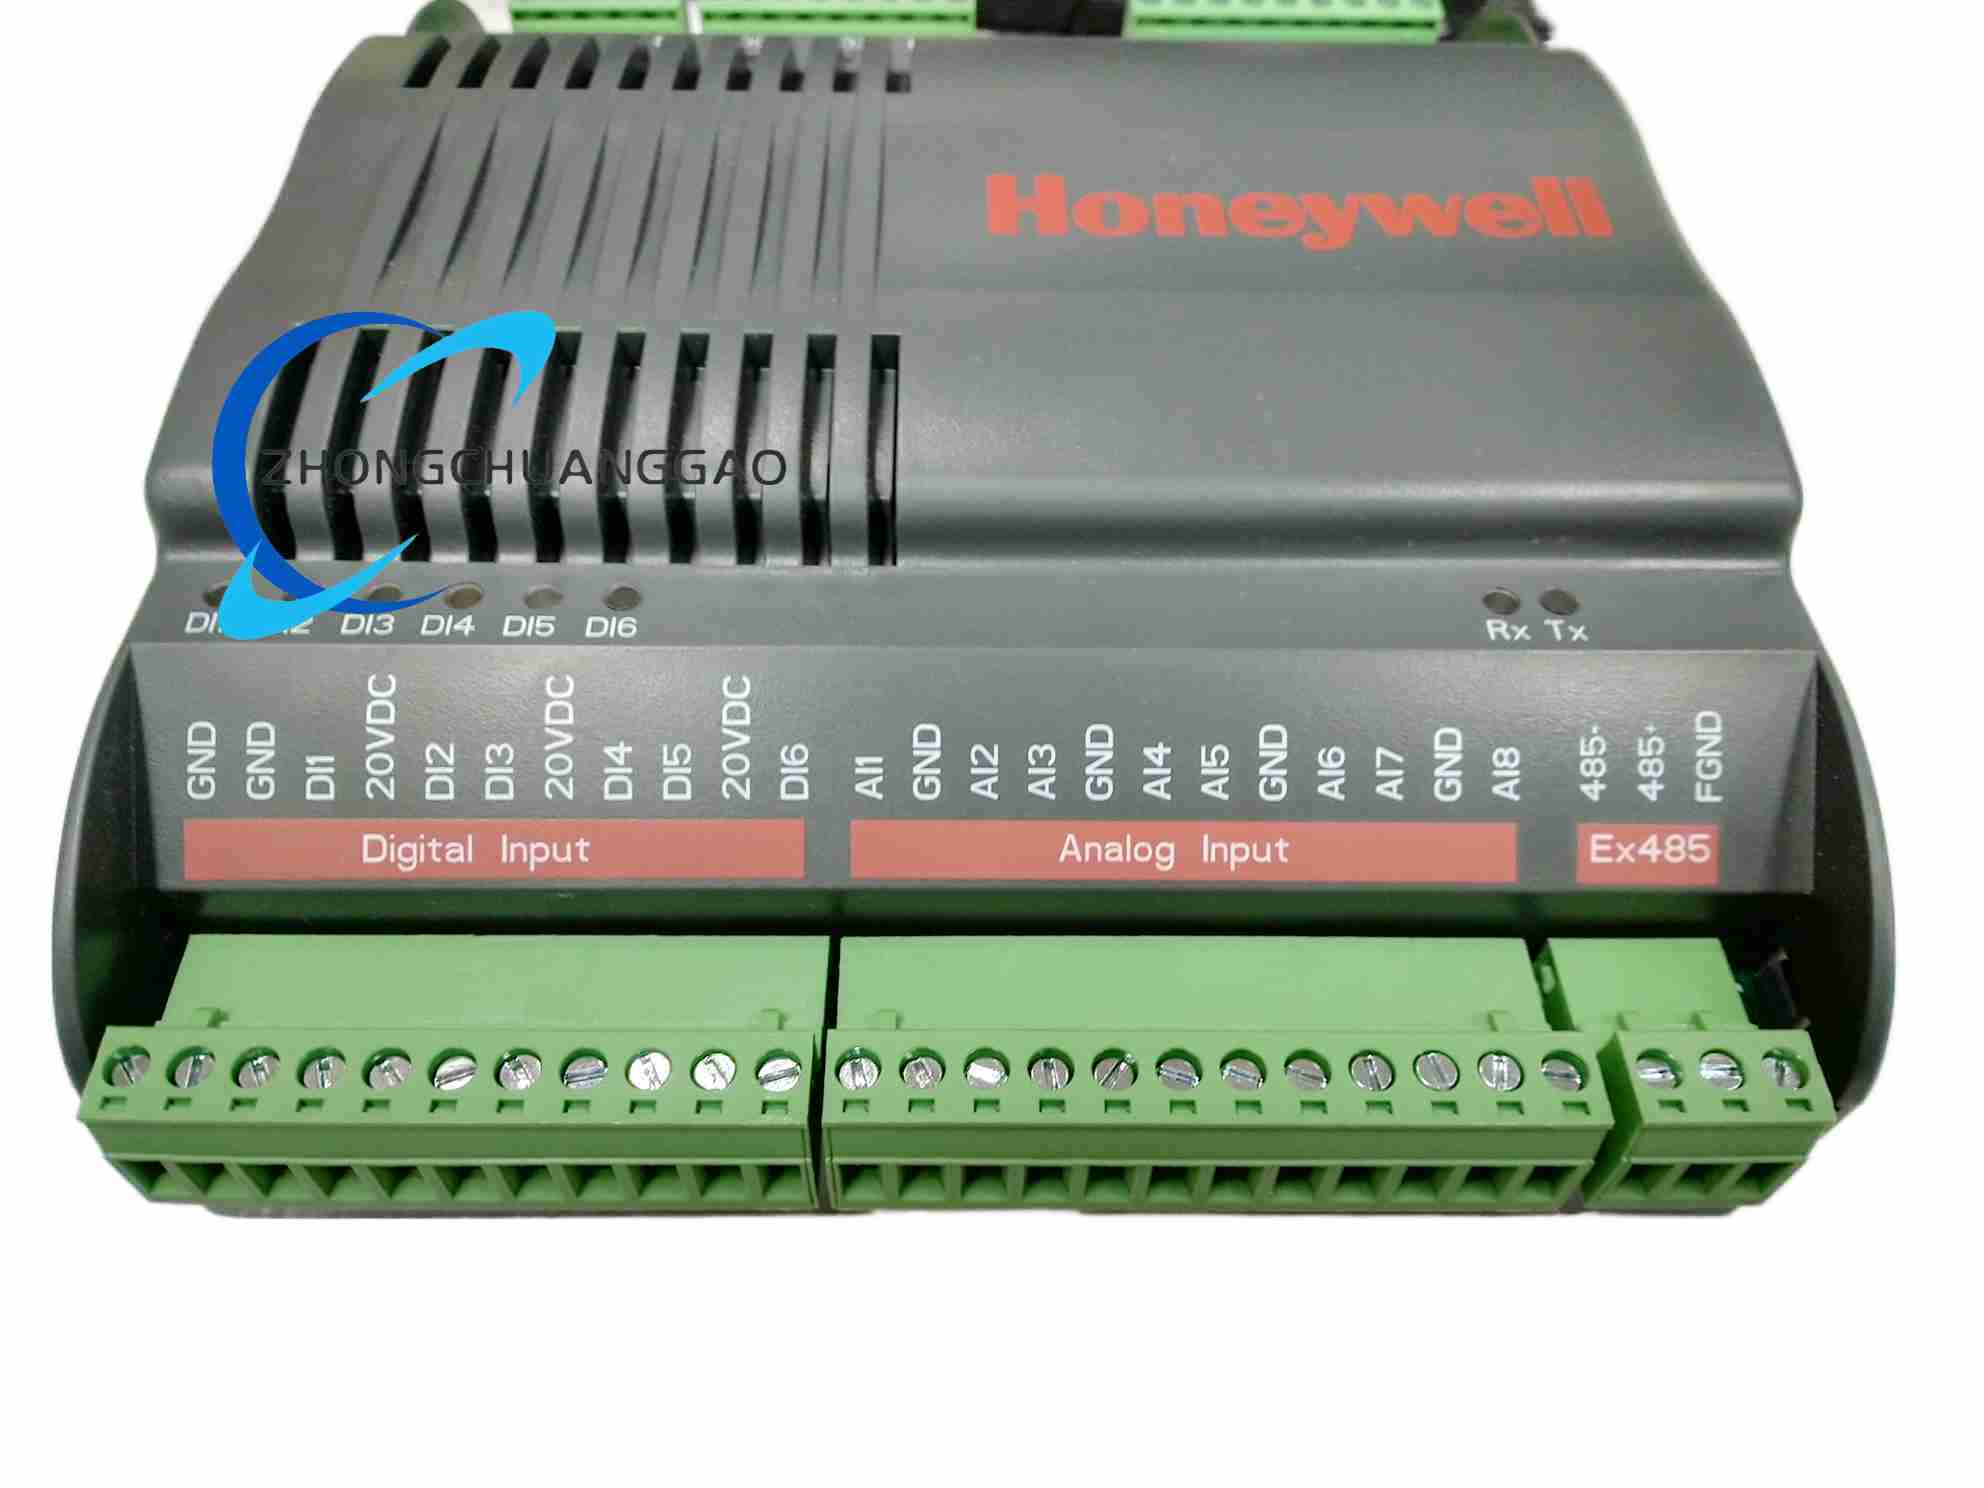
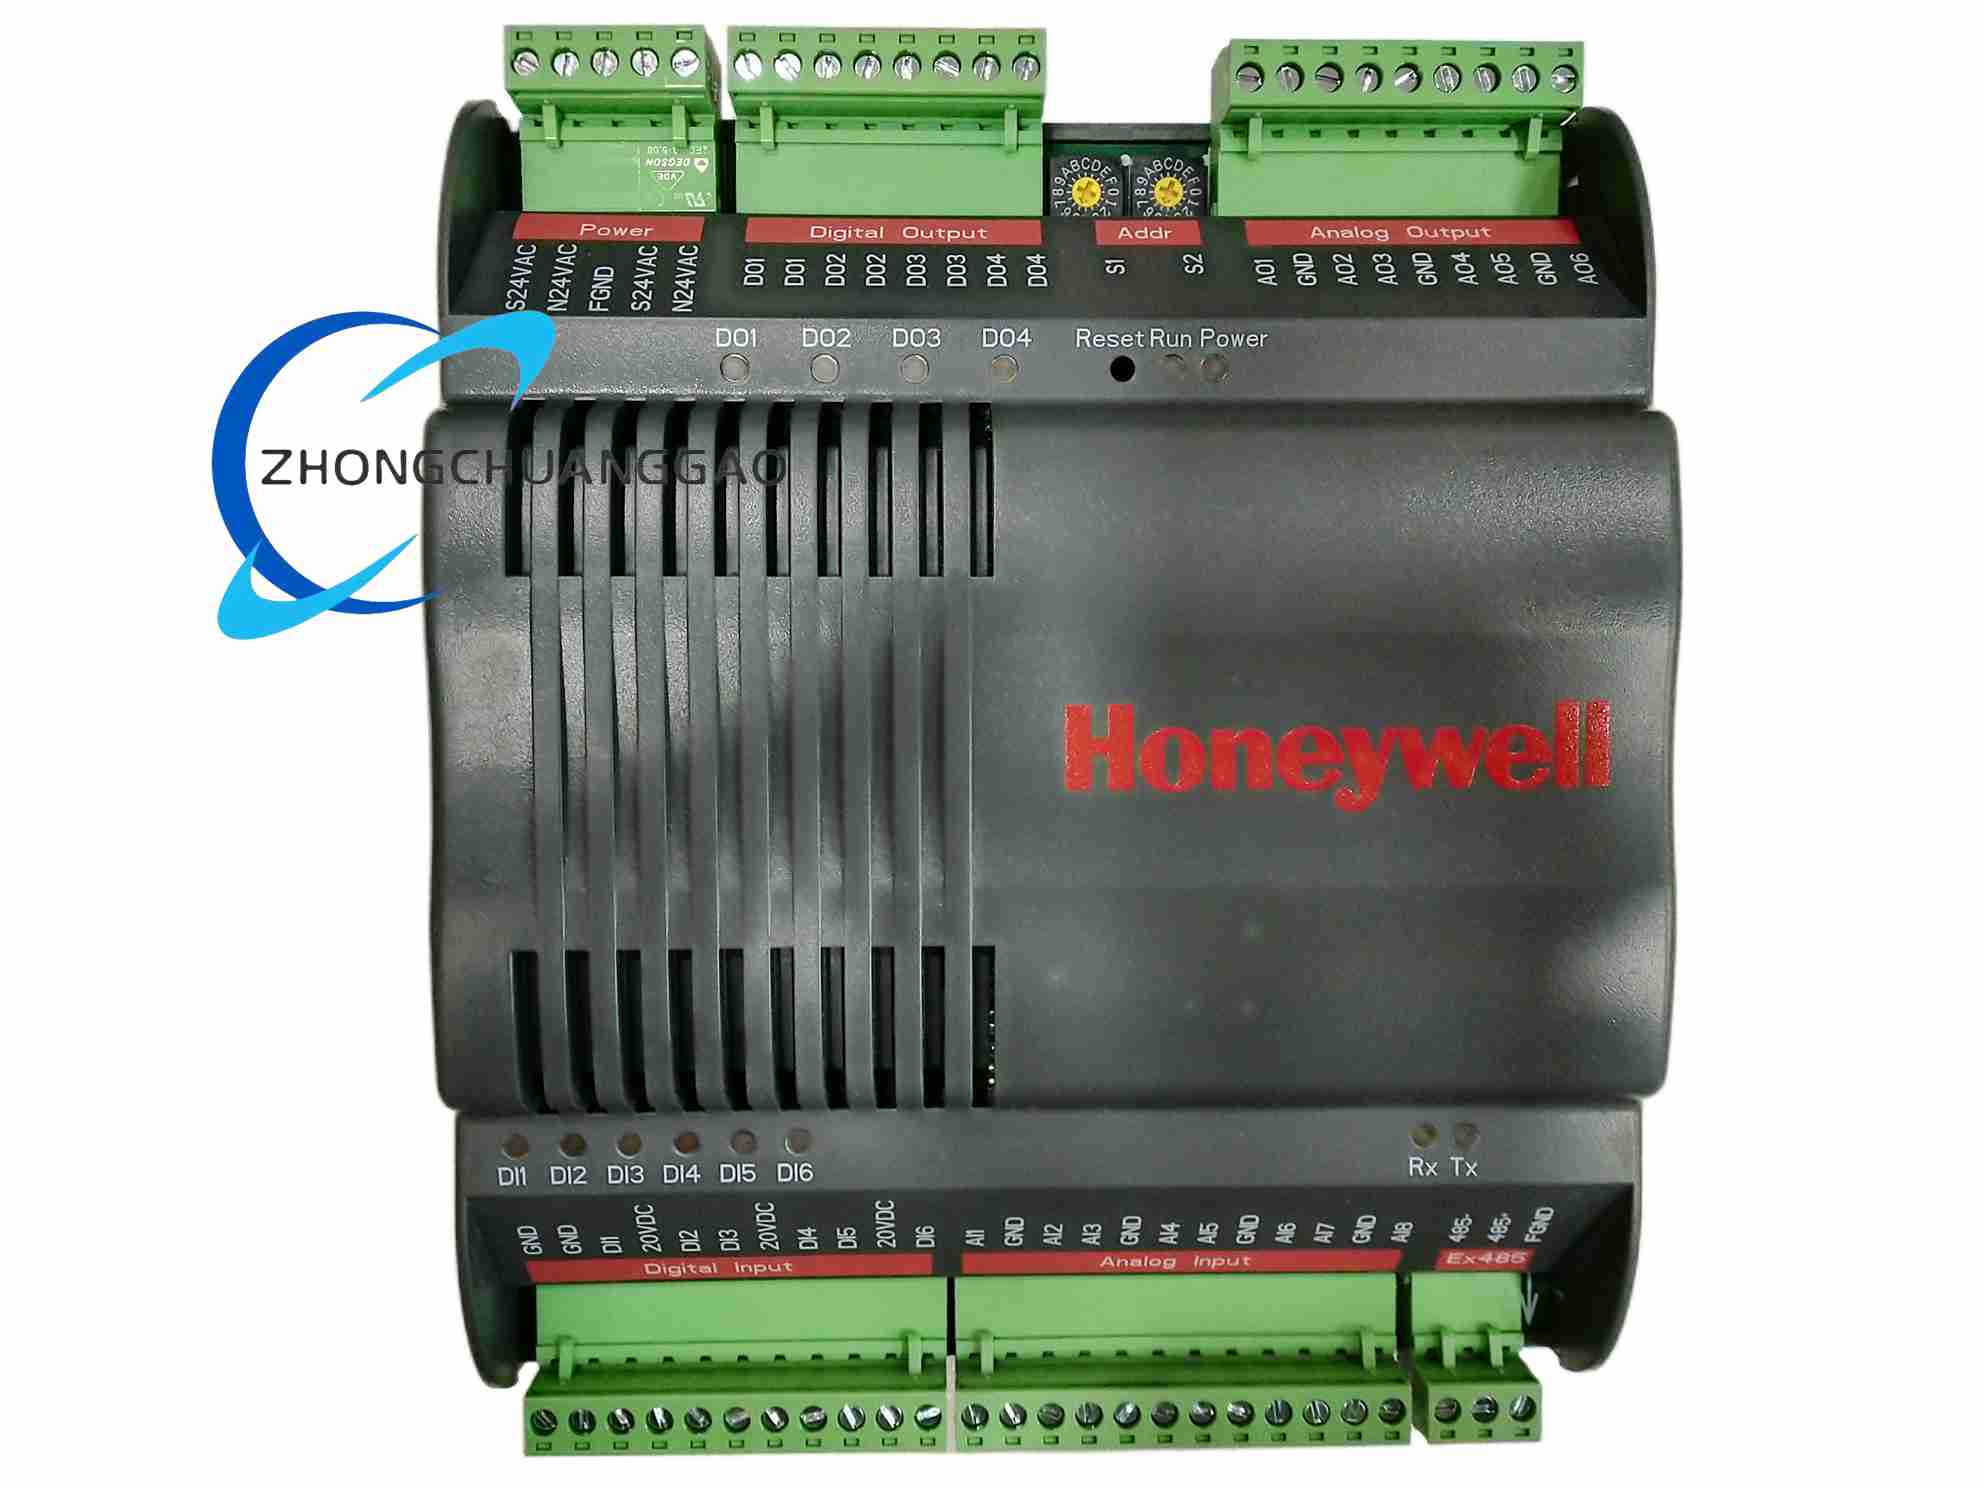
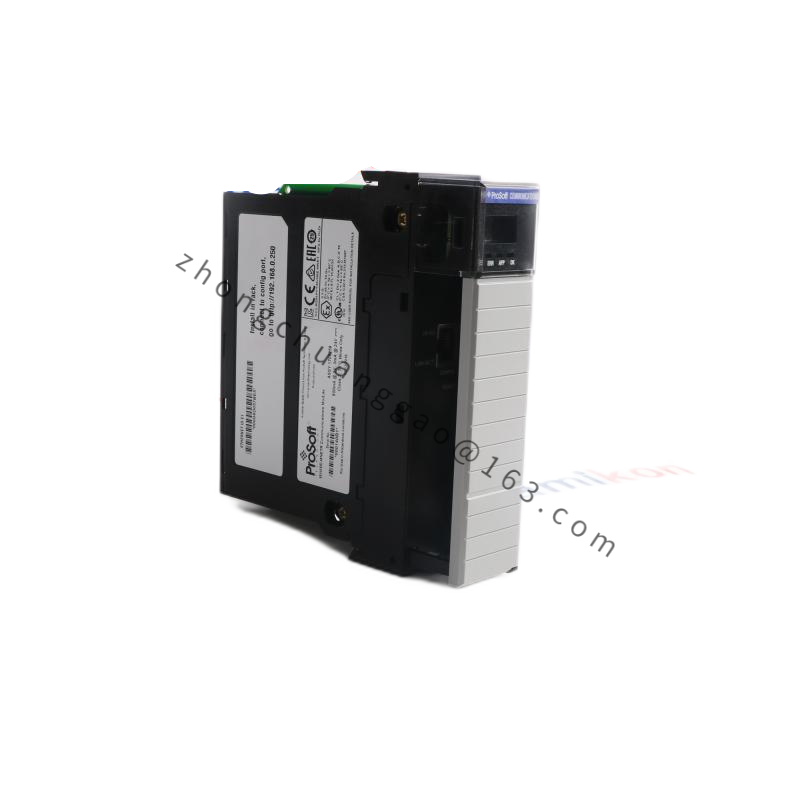
Compact DIN-rail enclosure with separated terminal zones for power, CAN bus, and control output. Front-panel LEDs and DIP switches. Rear DIN latch for tool-free removal. Shielded cable glands or screwed connector plates provide strain relief.
Working Principle
The module joins the CAN bus as a node. It receives command frames from the master controller, validates node ID and checksum, and converts digital setpoints into electrical control signals or forwards data to downstream devices. In motor applications, the module outputs 0 to 10 V to the drive, reads current and speed feedback, and returns encoded status frames to the host.
Installation Requirements
Mount on a 35 mm DIN rail inside a closed control cabinet. Use shielded twisted-pair CAN cable. Enable termination only at the first and last bus nodes. Keep CAN wiring separate from high-current motor power wiring. Supply regulated 24 VDC or the specified 9 to 30 VDC according to version.