Technical Specifications
Controller compatibility: Fanuc R 30iA robot controller. Some supplier listings also associate A16B 3200 0600 variants with R J3iC configurations; verify the exact hardware suffix before cross use.
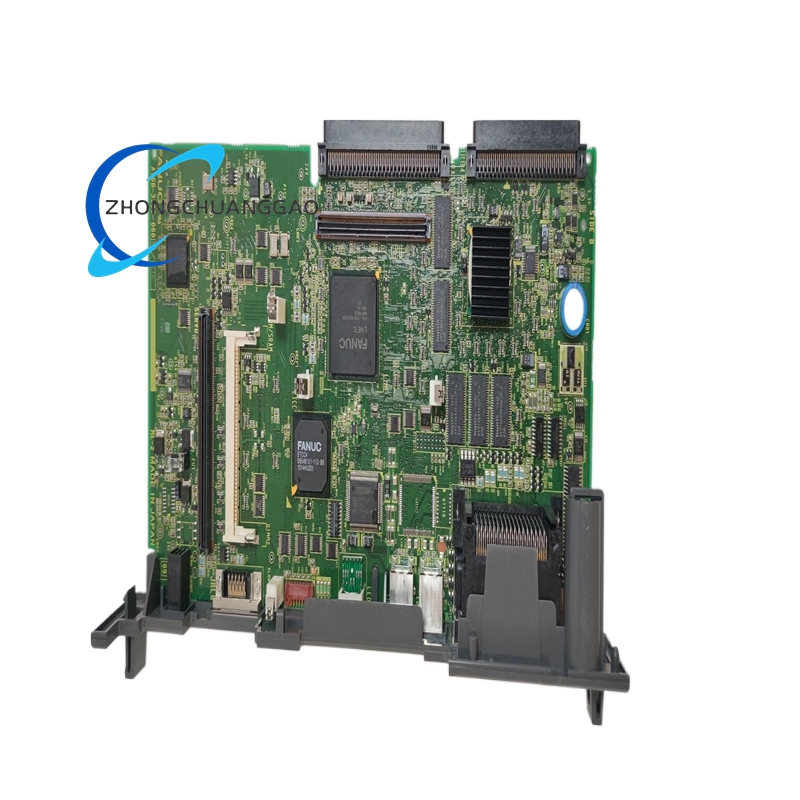
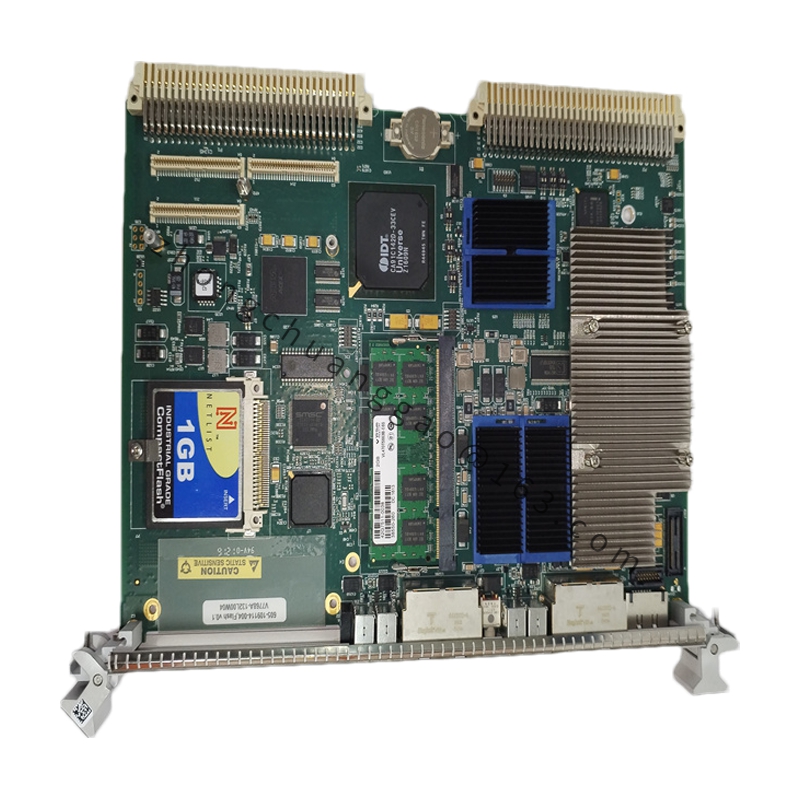
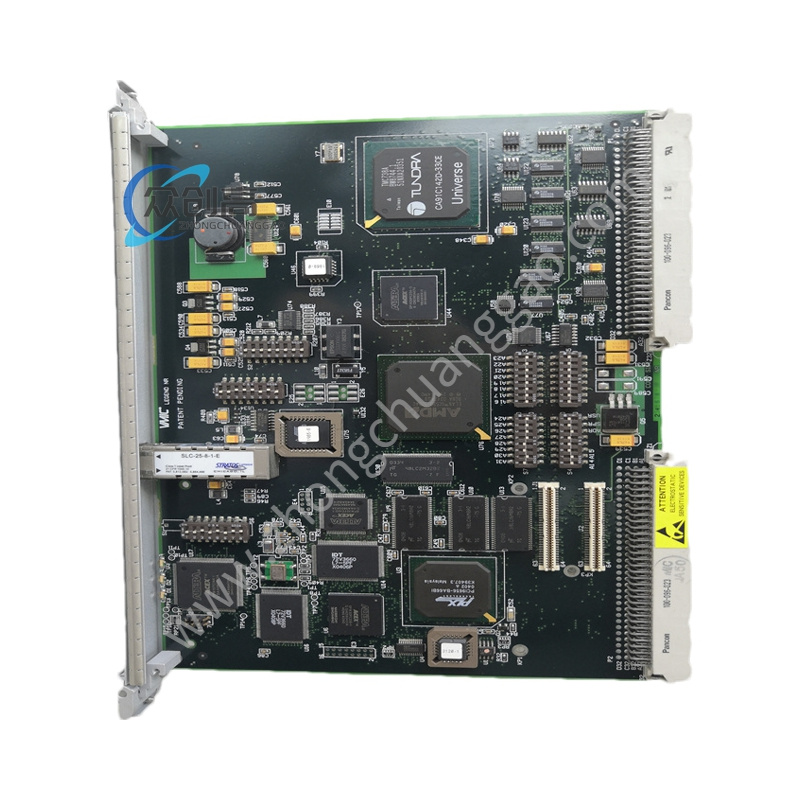
Board type: main CPU motherboard, backplane slot mount.
Control power: 24 V DC in listed R 30iA/R J3iC robot motherboard data.
Power consumption: approximately 45 W in listed R 30iA/R J3iC motherboard data.
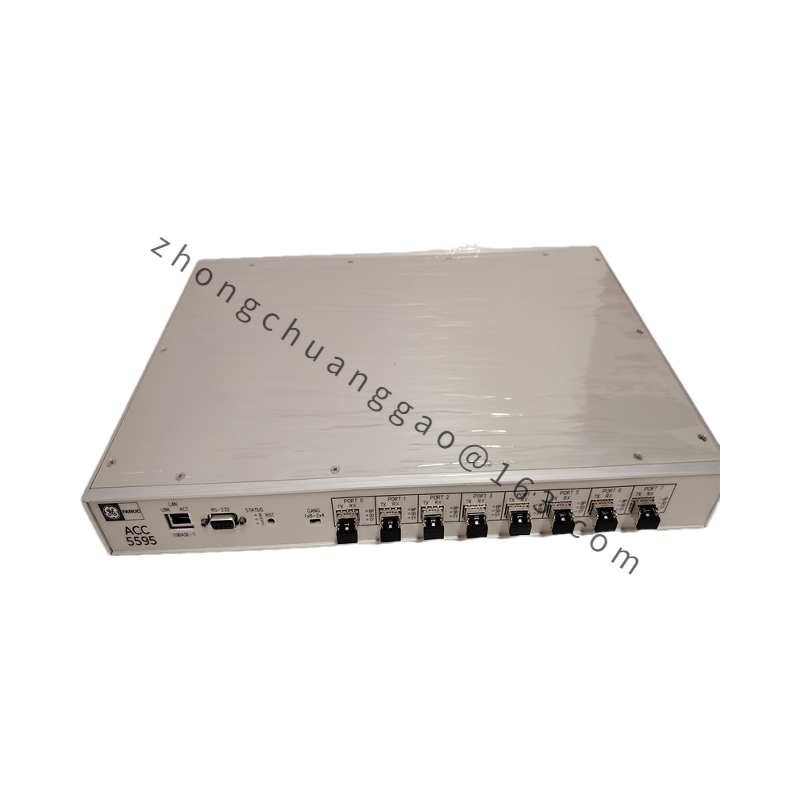
Servo communication: FSSB optical interfaces for robot servo drives.
Ethernet: dual Ethernet ports for programming, monitoring, and upper level communication.
Storage: PCMCIA and onboard FROM/SRAM memory support according to hardware version.
Expansion: servo subboard, FROM/SRAM, and fieldbus option slots according to version.
Operating temperature: 0 to 45 °C in standard R 30iA motherboard data; some robot motherboard listings state 0 to 60 °C.
Cooling: natural convection with control cabinet airflow.
Mounting: controller backplane or rack slot.
Functional Features
Real time execution of robot system software and application programs.
Multi axis trajectory interpolation and servo command distribution.
FSSB optical communication with robot servo amplifiers.
Ethernet programming, diagnostics, and cell network integration.
Safety monitoring for emergency stop, door interlock, and servo enable circuits.
Memory management for system firmware, variables, programs, and calibration data.
Application Scenarios
Fanuc R 30iA six axis robot controllers.
Material handling and palletizing cells.
Welding, assembly, and machining support robots where R 30iA hardware is specified.
Robot maintenance, motherboard replacement, and controller refurbishment.
Performance Parameters
Multi axis closed loop motion processing through FSSB servo links.
FROM/SRAM based firmware and program storage.
Real time alarm processing for servo, I/O, safety, and communication faults.
Continuous CPU operation under cabinet cooled industrial environment.
Material And Construction
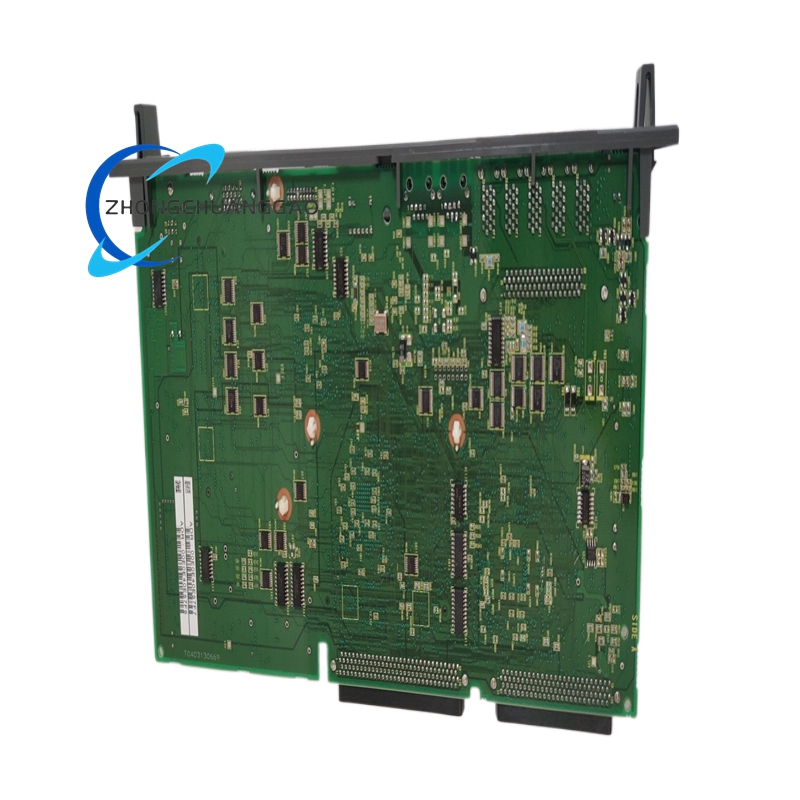
Multilayer printed circuit board with central processor and memory devices.
FSSB optical connectors, Ethernet ports, and serial/service interfaces.
Memory card and option subboard sockets.
Backplane edge or pin connectors for power and bus distribution.
Heatsinks or thermal pads according to processor and bridge devices.
Working Principle
The motherboard boots robot system software from onboard or card memory. It receives teach pendant, I/O, and network commands, calculates interpolated motion trajectories, and transmits servo commands over FSSB. Encoder and amplifier feedback return through the serial link. Safety circuits are monitored continuously, and fault data are reported to the teach pendant and diagnostics memory.
Installation Requirements
Install in the correct R 30iA backplane slot orientation.
Connect 24 V DC control power according to the controller schematic.
Attach FSSB fibers, Ethernet cables, I/O buses, and memory cards after board seating.
Verify backplane connector alignment before final fixation.
Ensure cabinet airflow and temperature remain within the specified range.
Usage Precautions
Perform a full FROM/SRAM backup before removing the original motherboard.
Verify backup battery health to preserve position and program data.
Use antistatic wrist straps and handle the board by its edges.
Install only firmware and option versions matched to the robot model.
Do not force the board into misaligned backplane connectors.