Technical Specifications
Rated output: 2.7 kW.
Rated voltage: 168 V AC output class.
Input supply: 200 to 240 V AC, 3 phase, 50/60 Hz.
Maximum speed: 3000 rpm.
Rated current: 9.6 A.
Stall torque: 12 Nm.
Stall current: 13 A.
Rated frequency: 200 Hz.
Power factor: 98 percent.
Poles: 8.
Winding: wye configuration.
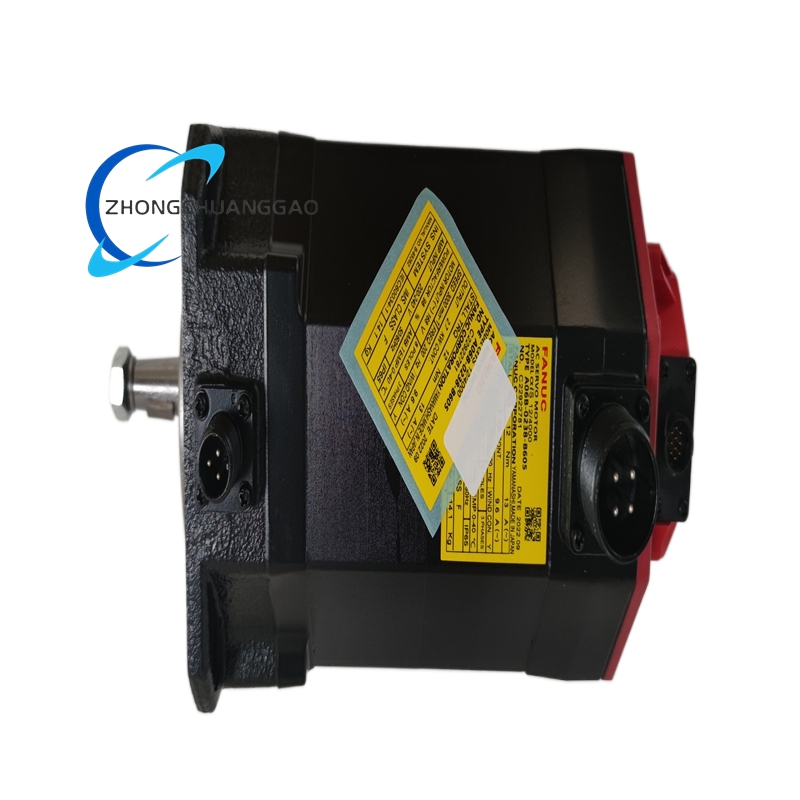
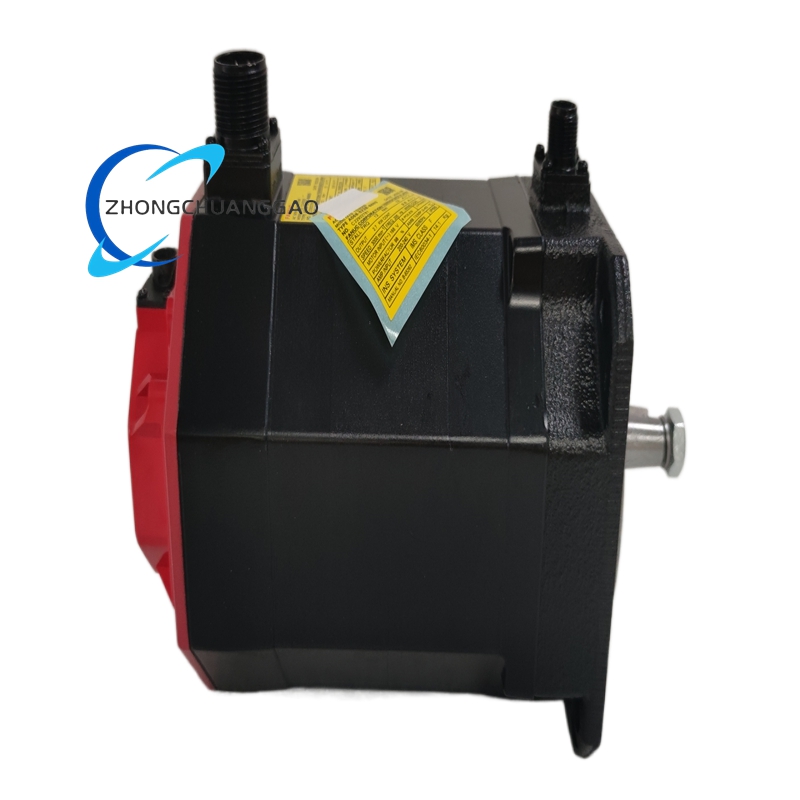
Shaft: tapered shaft with keyway, 35 mm diameter.
Brake: 90 V DC holding brake.
Encoder: a64iA absolute pulse coder.
Protection class: IP65.
Insulation class: Class F.
Functional Features
Absolute encoder feedback for high resolution position detection.
Tapered keyed shaft for secure coupling connection.
DC holding brake for axis retention during power loss and dwell.
IP65 enclosure for dust and coolant resistant operation.
High power density for compact machine tool axis designs.
Application Scenarios
CNC milling machine feed axes.
CNC turning machine tool slides.
Industrial robotic joint drives.
Precision assembly and handling systems.
Automated production lines requiring repeatable positioning.
Performance Parameters
Continuous torque support at 12 Nm stall rating.
Stable 3000 rpm maximum rotational operation.
98 percent power factor for efficient three phase drive interaction.
Absolute feedback resolution suitable for closed loop servo control.
Material And Construction
Aluminum motor frame and end brackets.
Permanent magnet rotor assembly.
Insulated stator windings rated to Class F.
Sealed encoder housing with absolute feedback optics or electronics.
Tapered alloy shaft with keyway and brake stack.
Working Principle
The servo amplifier sends three phase current to the stator according to position commands. The permanent magnet rotor follows the rotating magnetic field. The absolute encoder measures rotor position and returns feedback to the controller. The brake engages electrically controlled DC power to hold the shaft when commanded.
Installation Requirements
Mount the motor using the prescribed foot, flange, or machine housing arrangement.
Align the coupling concentrically with the machine shaft.
Connect shield grounded motor power cables to the servo amplifier.
Connect the encoder cable to the designated absolute feedback port.
Verify brake voltage and release circuit before automatic operation.
Usage Precautions
Do not operate without encoder feedback connection.
Confirm brake release voltage before starting motion.
Avoid coolant ingress beyond the IP65 sealed interfaces.
Use proper locking procedures before mechanical coupling work.
Periodically inspect brake function, encoder cable, and stator insulation.