Technical Specifications
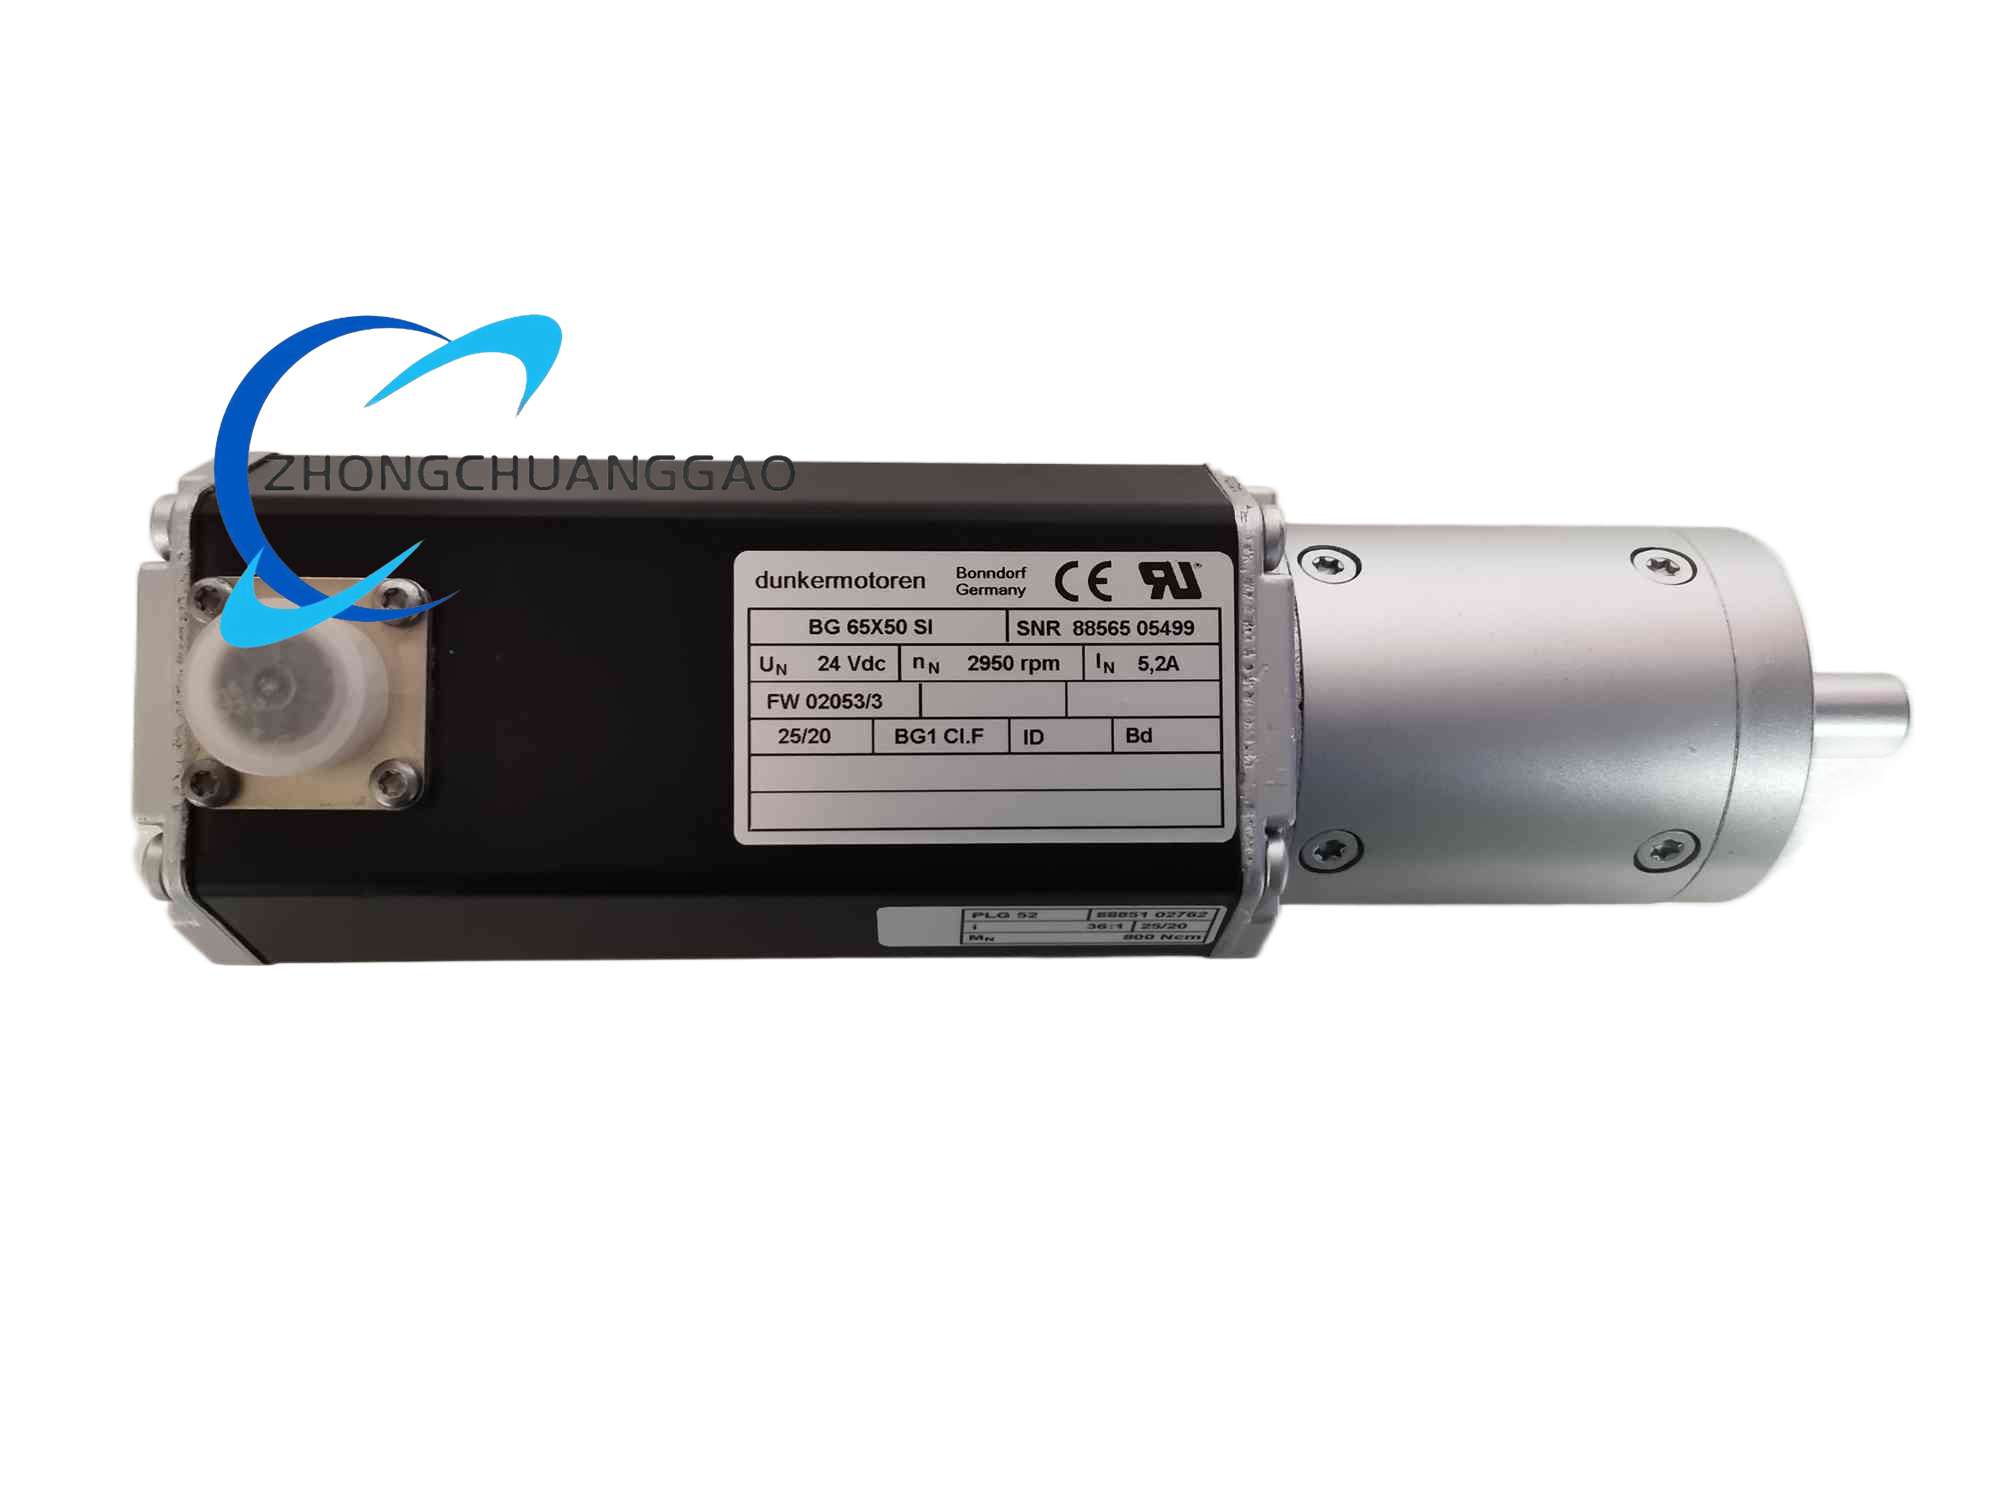
Rated voltage: 48 V DC.
Rated speed: 4500 rpm.
Rated torque: 0.65 Nm.
Rated power: 306 W.
Peak torque: 2.3 Nm.
Terminal resistance, line-to-line: 0.55 ohm.
Terminal inductance, line-to-line: 0.35 mH.
Rotor inertia: 82 gcm².
Weight: 0.85 kg.
Protection class: IP54 standard; integrated smart-motor versions may offer different ingress ratings.
Operating temperature: −20 to +55°C for the referenced industrial configuration.
Functional Features
Neodymium permanent magnets provide high torque and low cogging.
Precision-wound stator improves efficiency and thermal performance.
Compatible with Hall sensors, incremental encoders and resolvers for closed-loop control.
Direct integration with Dunkermotoren gearboxes, brakes and controllers.
High dynamic acceleration and deceleration for frequent start-stop cycles.
Application Scenarios
Robotic joints, articulated arms and AGV drivetrains.
CNC feeding axes, packaging machines, textile equipment and printers.
Medical diagnostics, surgical assistants and patient-positioning systems.
Semiconductor handling and cleanroom automation where brushless operation is required.
Performance Parameters
Torque-to-volume ratio is optimized for space-limited designs.
Continuous current capability depends on cooling method, ambient temperature and winding version.
Encoder or Hall feedback determines commutation quality, positioning accuracy and speed stability.
Material Composition
Rotor uses high-energy neodymium-iron-boron magnets.
Stator uses laminated electrical steel with insulated copper windings.
Housing uses aluminum or coated steel according to the configured frame and cooling design.
Output shaft uses hardened steel; seals and bearings are selected for the protection class.
Structural Characteristics
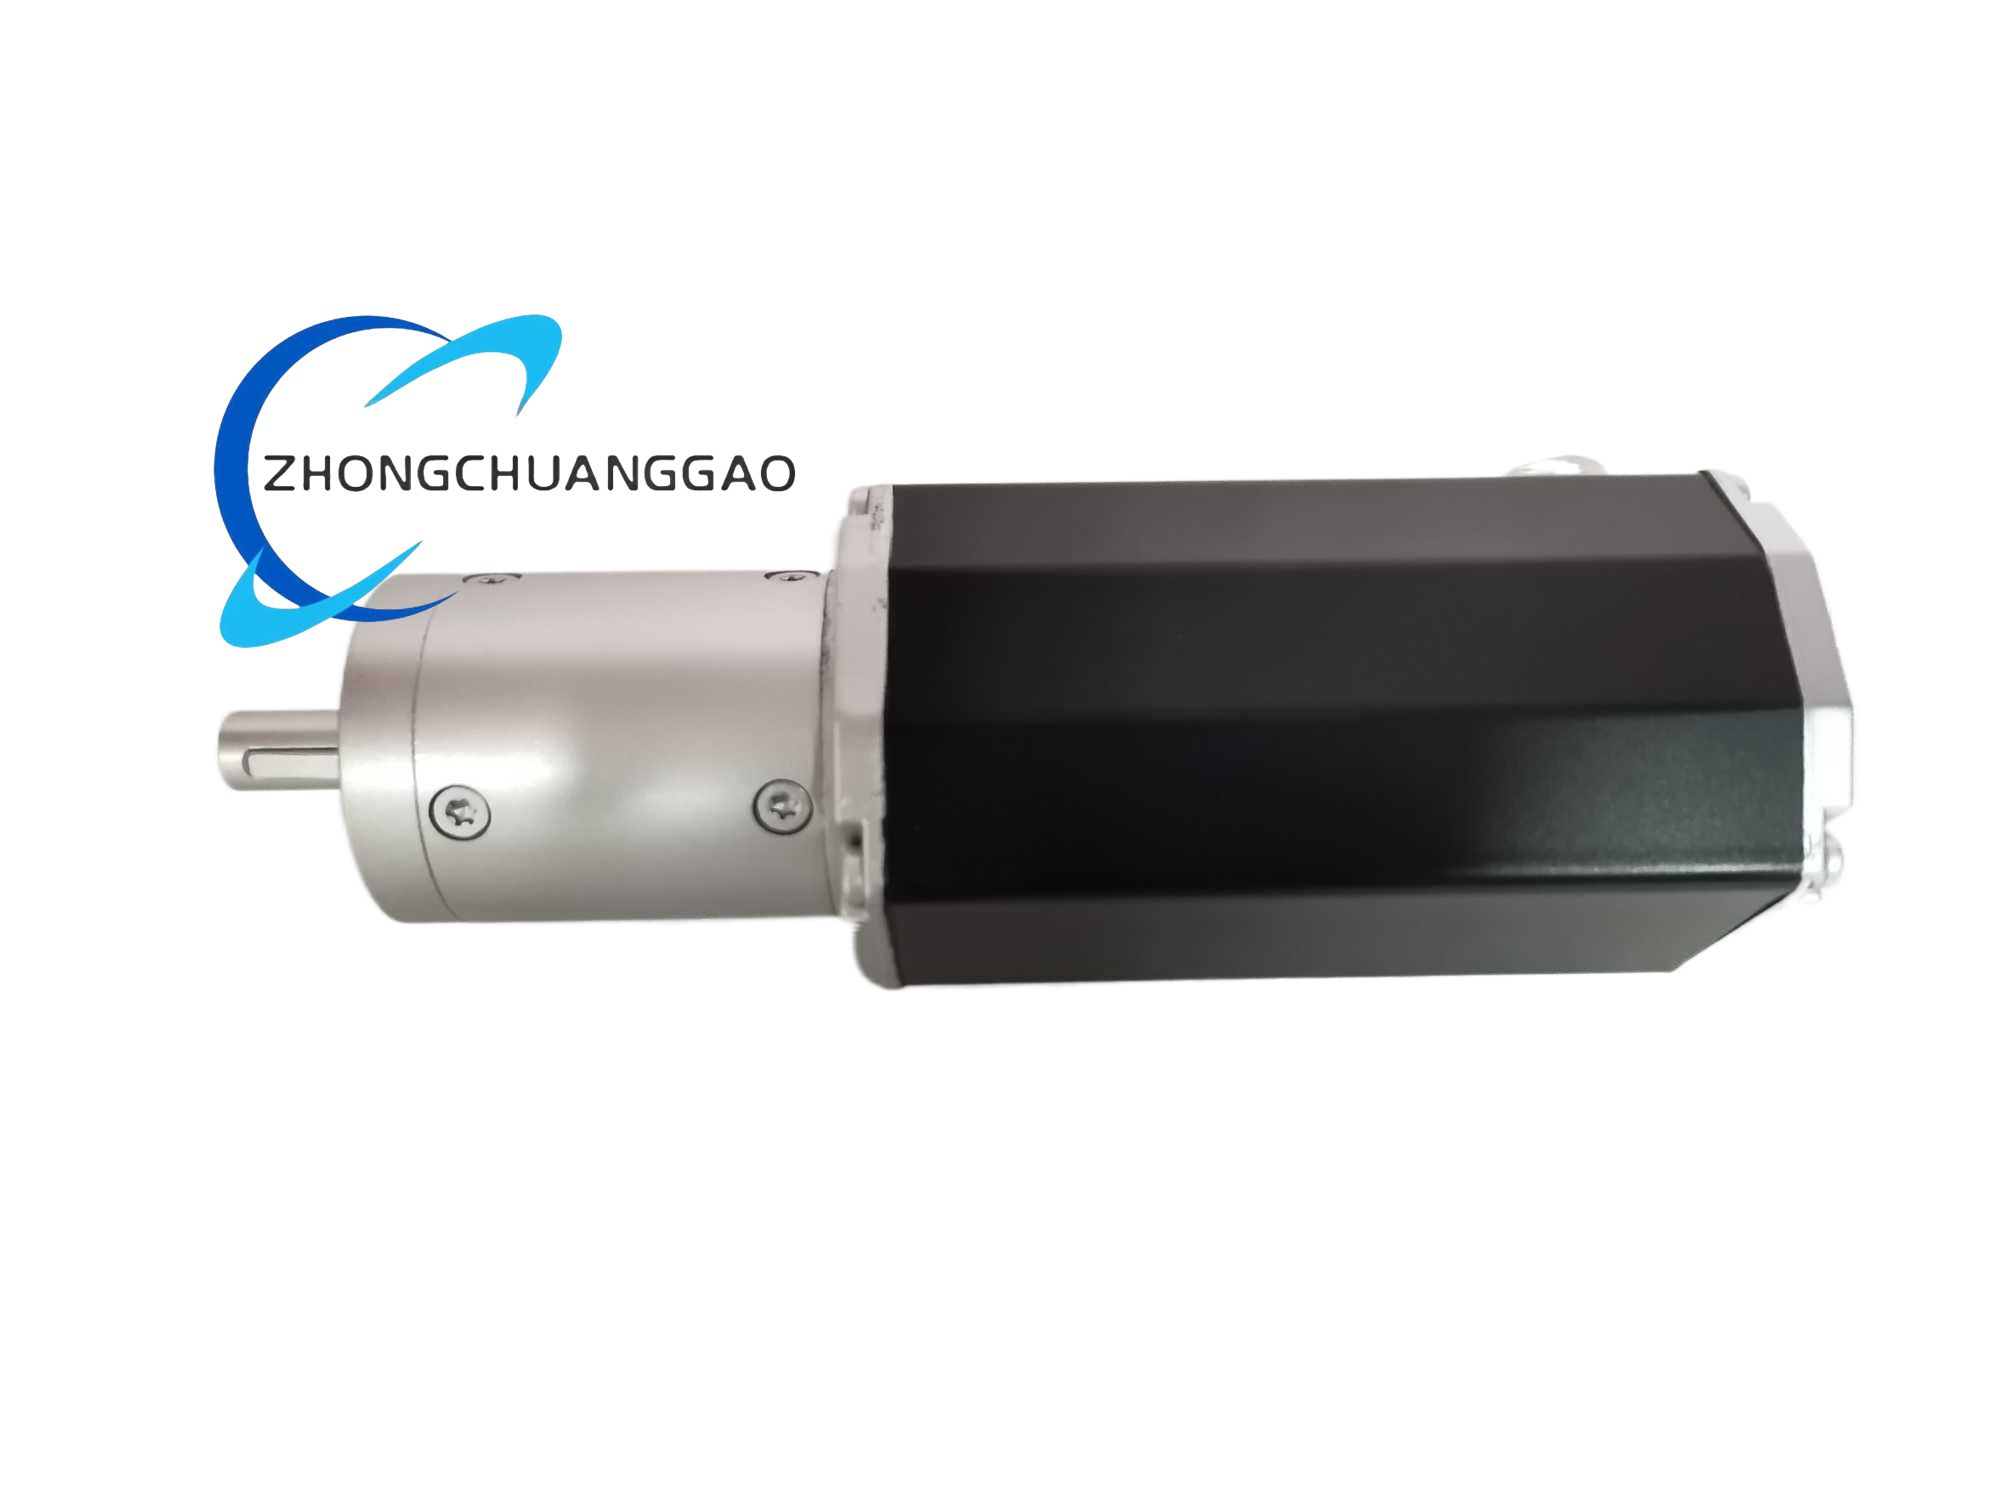
Compact cylindrical motor body with integral stator and rotor assembly.
Optional frameless construction allows direct machine embedding without coupling.
Feedback device mounted on the rear shaft end.
Terminal or connector outlet configured for the specified controller interface.
Working Principle
The controller energizes stator phases according to rotor position feedback.
Permanent magnets on the rotor create a fixed field; sequential stator fields produce rotational torque.
Electronic commutation replaces mechanical brushes, reducing wear and enabling high-speed, maintenance-light operation.
Closed-loop feedback regulates current, speed and position.
Installation Requirements
Mount using the specified flange, shaft tolerance and coupling alignment.
Provide 48 V DC supply sized for rated and peak current demand.
Install encoder, resolver or Hall wiring according to the controller manual.
Ensure ventilation or forced cooling when operating near continuous peak torque.
Use approved gearbox and brake combinations for the BG65 platform.
Usage Precautions
Avoid sustained overload above peak torque and thermal limits.
Check bearing load, radial force and shaft alignment during integration.
Use correct commutation sequence and encoder polarity before enabling servo control.
Protect the motor against moisture, coolant ingress and excessive ambient temperature when IP rating is insufficient.