Functional Features
High-bandwidth PID current and motion control, automatic motor parameter identification, regenerative energy return to the shared DC bus, EtherCAT synchronization for multi-axis systems, front status LEDs and diagnostics, integrated safety torque-off.
Application Scenarios
Metal-forming presses, printing presses, textile machines, packaging palletizers, woodworking CNC centers, battery manufacturing lines, heavy conveyor and web-handling systems.
Performance Parameters
30 A continuous output, 200% short-time overload, 540 V DC bus, EtherCAT cyclic motion commands, resolver or EnDat feedback, 0 to 55°C cabinet ambient, rapid torque response through IGBT power stage.
Material Composition
Flame-retardant aluminium extrusion housing, direct-bonded-copper IGBT substrate, copper liquid-cooling manifold, silver-plated copper DC-bus terminals, industrial FR4 control board with conformal coating.
Structural Characteristics
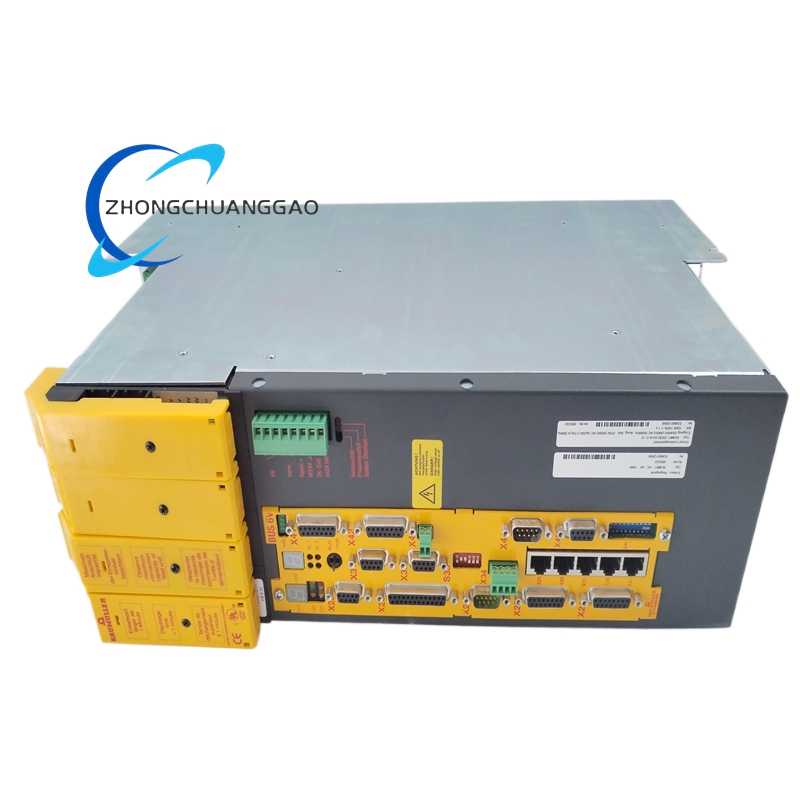
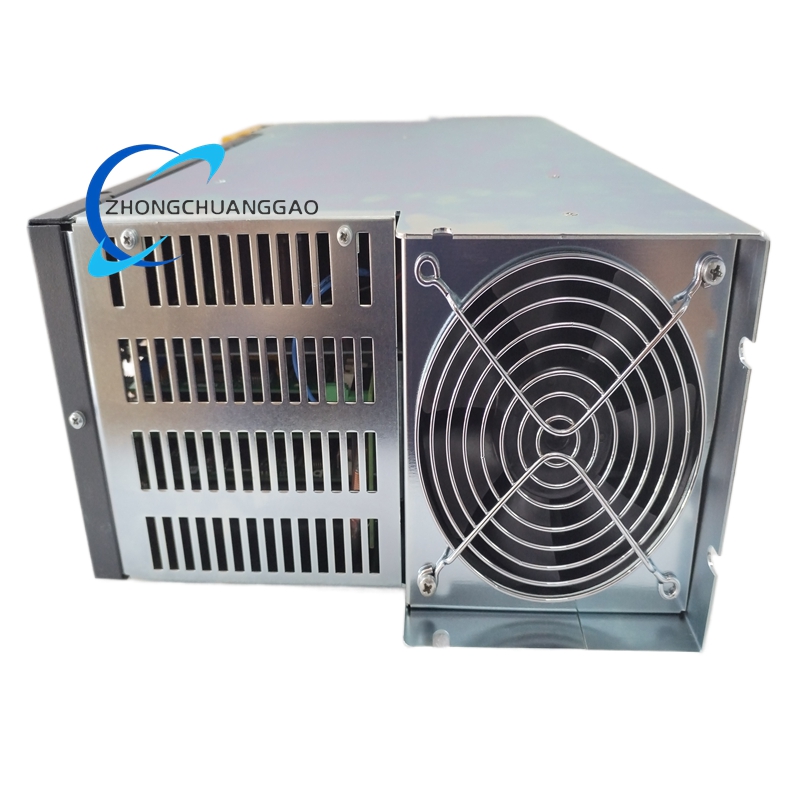
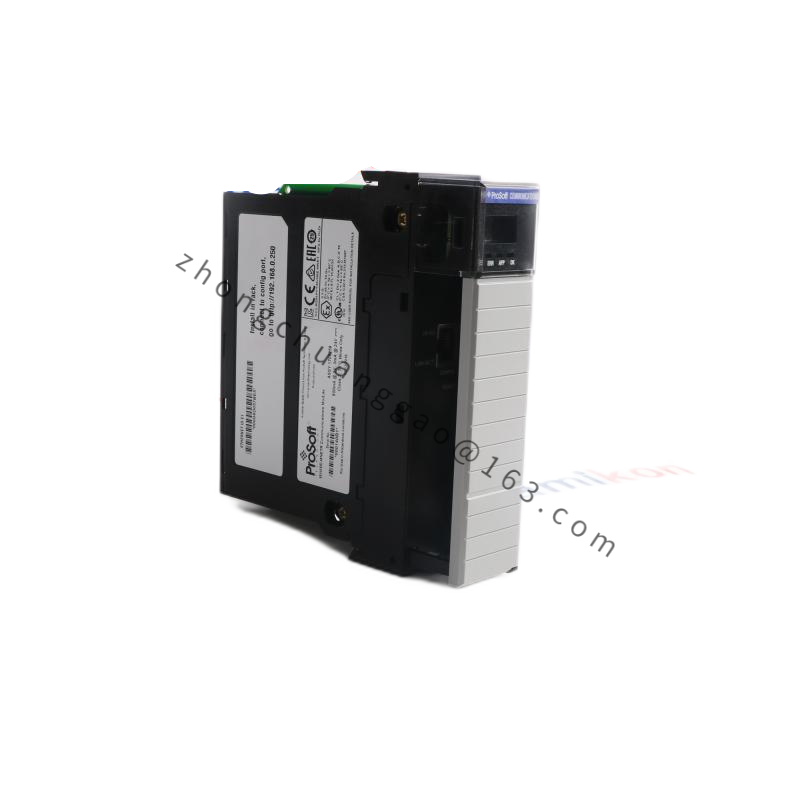
Rack-mount single-width drive module, bottom liquid-cooling baseplate with inlet and outlet ports, front diagnostic display and LEDs, rear high-current DC-bus and motor terminals, side pluggable encoder, I/O and EtherCAT terminal module.
Working Principle
The EtherCAT master sends position and speed setpoints to the drive. The DSP executes current, speed and position loops using encoder or resolver feedback. The IGBT inverter converts 540 V DC-bus power into variable-frequency three-phase output for the motor. Regenerated braking energy is returned to the shared DC bus. The STO circuit disables IGBT gate drive when a safety condition is triggered.
Installation Requirements
Insert the module into the compatible Baumuller BUM61 rack and lock retention latches. Connect the liquid-cooling loop with correct flow, pressure and leak-free fittings. Connect the rear DC-bus bar and shielded motor cables with specified torque. Terminate EtherCAT with the correct topology and resistances. Maintain cabinet temperature below 55°C with auxiliary ventilation if required.
Usage Precautions
Never operate without active liquid-coolant circulation. Do not remove or insert the module while the 540 V DC bus is energized. Perform motor auto-tuning after motor replacement or load change. Test insulation resistance of motor cables periodically. Keep the cooling plates free from blockage and contamination.